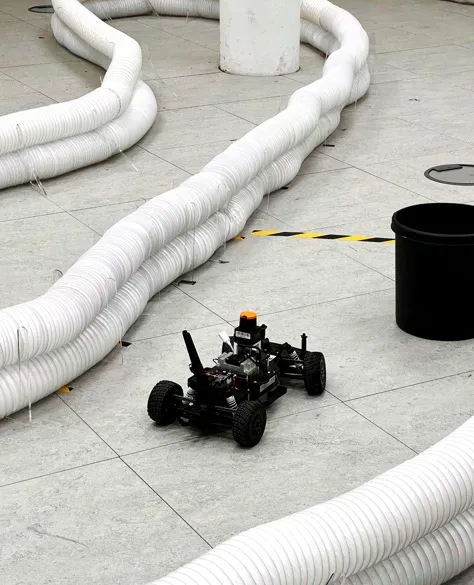
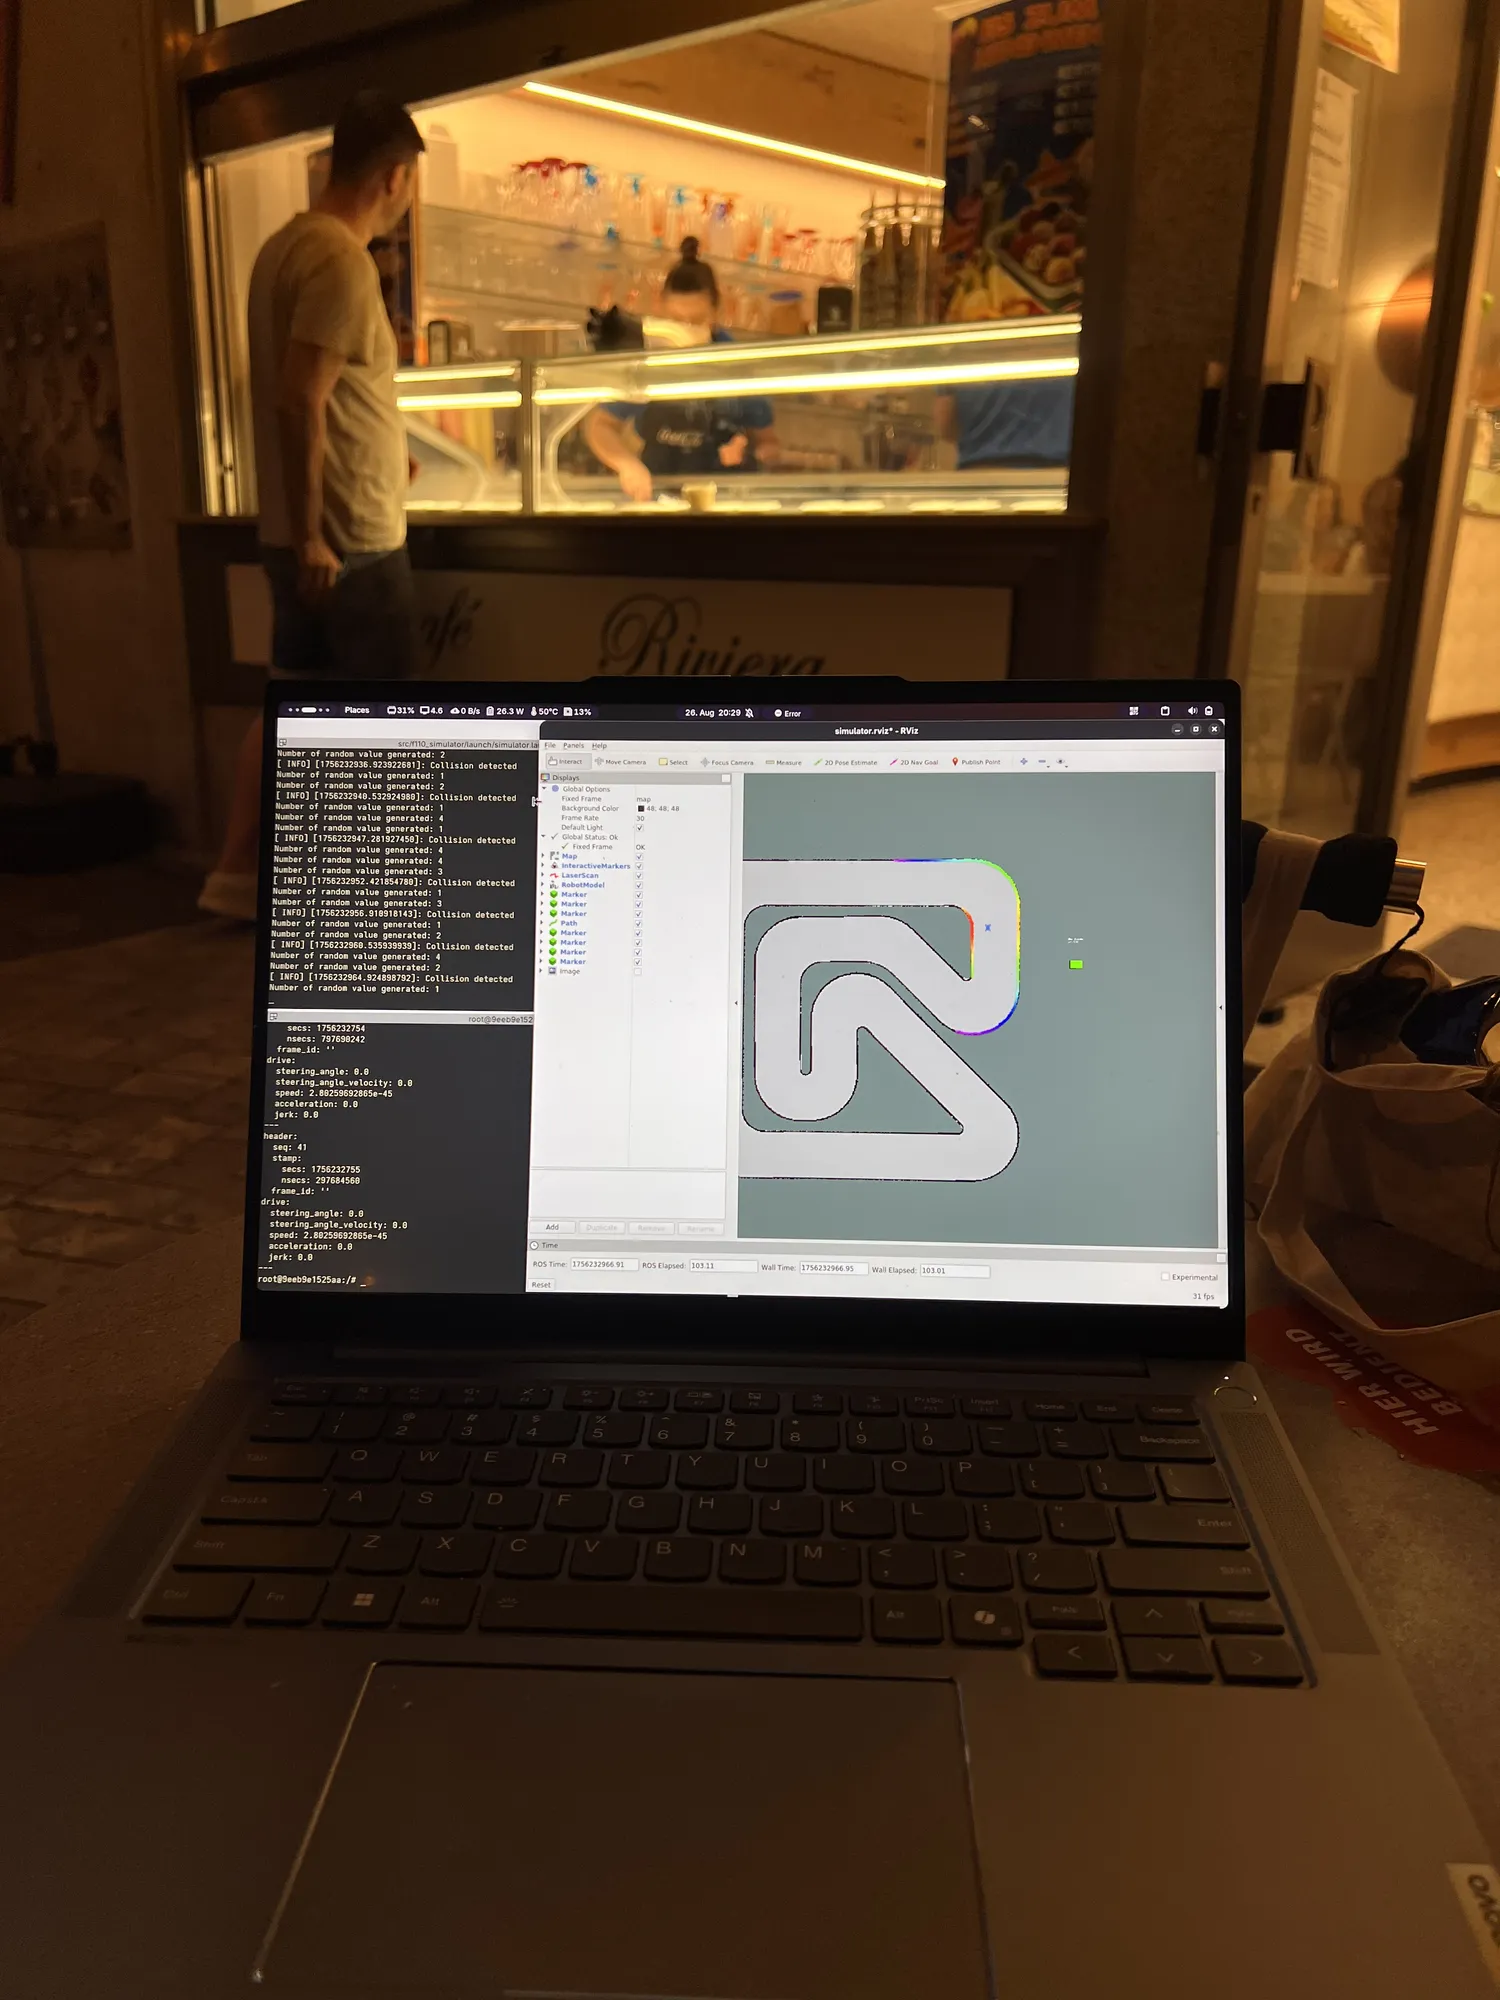
A two-week lab project at TUM: get an F1Tenth car around the track fast, without overcomplicating the controller.
From wall-following to gap-following
I started with a PID wall-following controller on the LiDAR scan, then switched to Follow the Gap, which steers toward the largest open space in each scan. That alone made the car about 30% faster.
Speed modulation came last: fast on the straights, slower into corners, which improved both lap time and stability.