A robot that gets from A to B even when B is on another floor, aimed at hospital supply runs, last-mile delivery and logistics across factory floors.
How it works
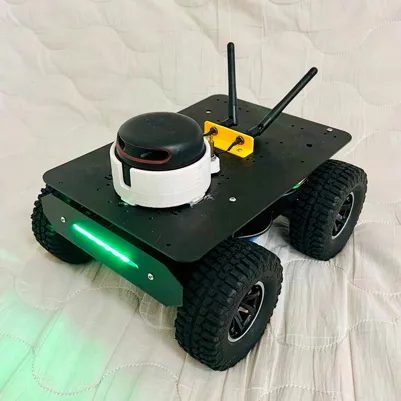
I sourced the base platform directly from vendors and put a Jetson Nano on it running ROS 2, talking to the STM32 base driver. Each floor is mapped with LiDAR SLAM, then localized with AMCL and navigated with Nav2. LiDAR odometry is fused with the IMU for better accuracy.
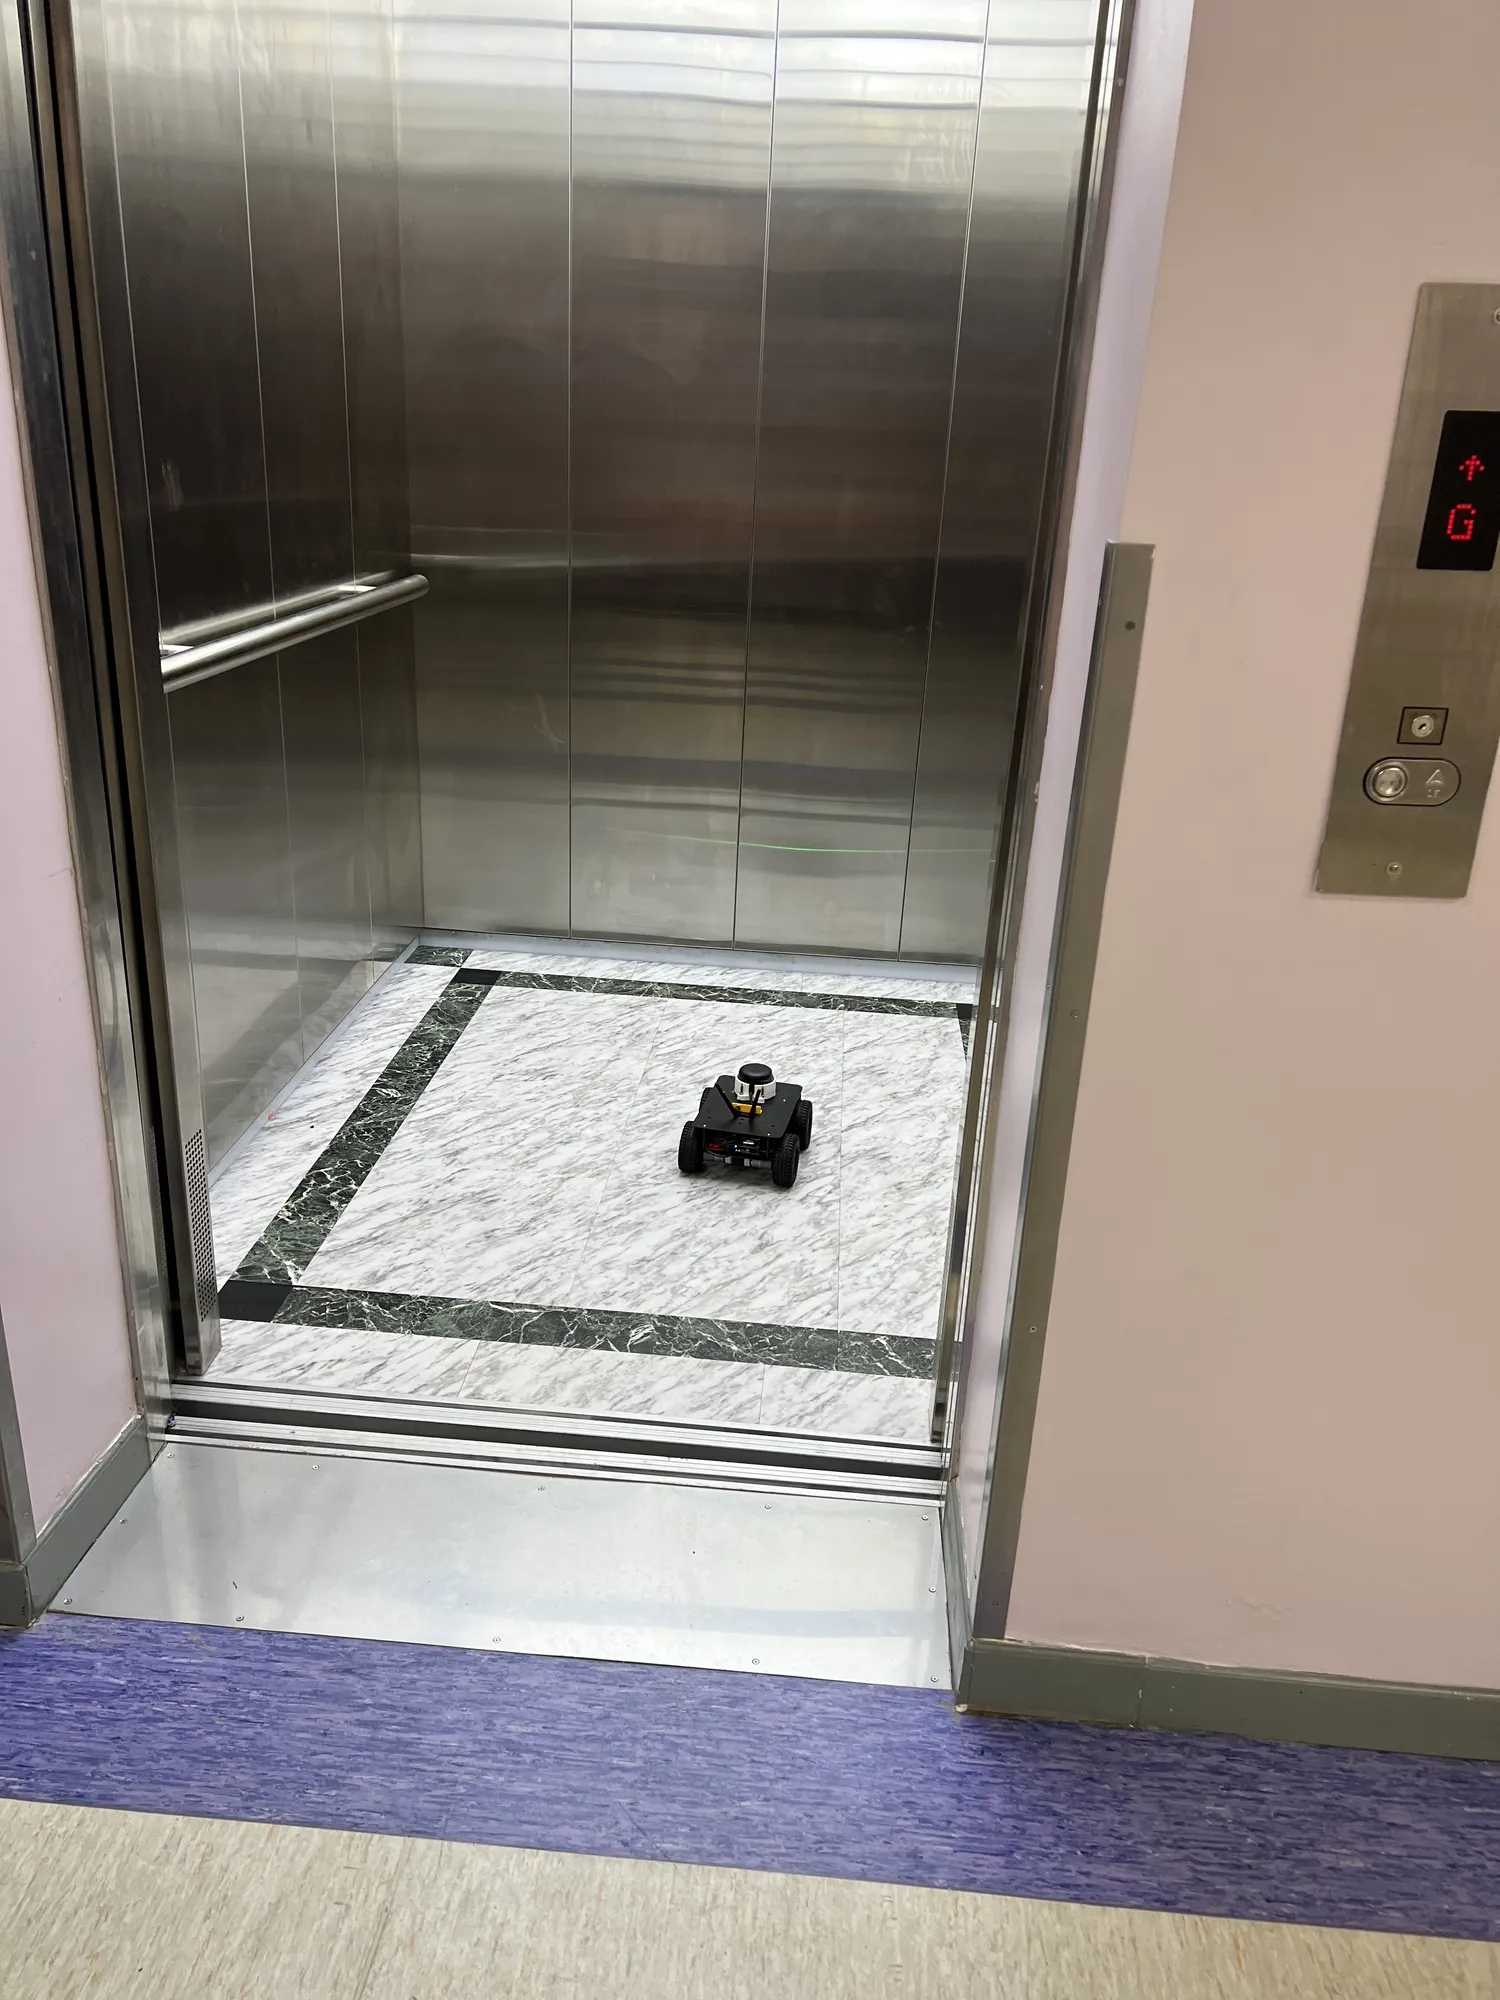
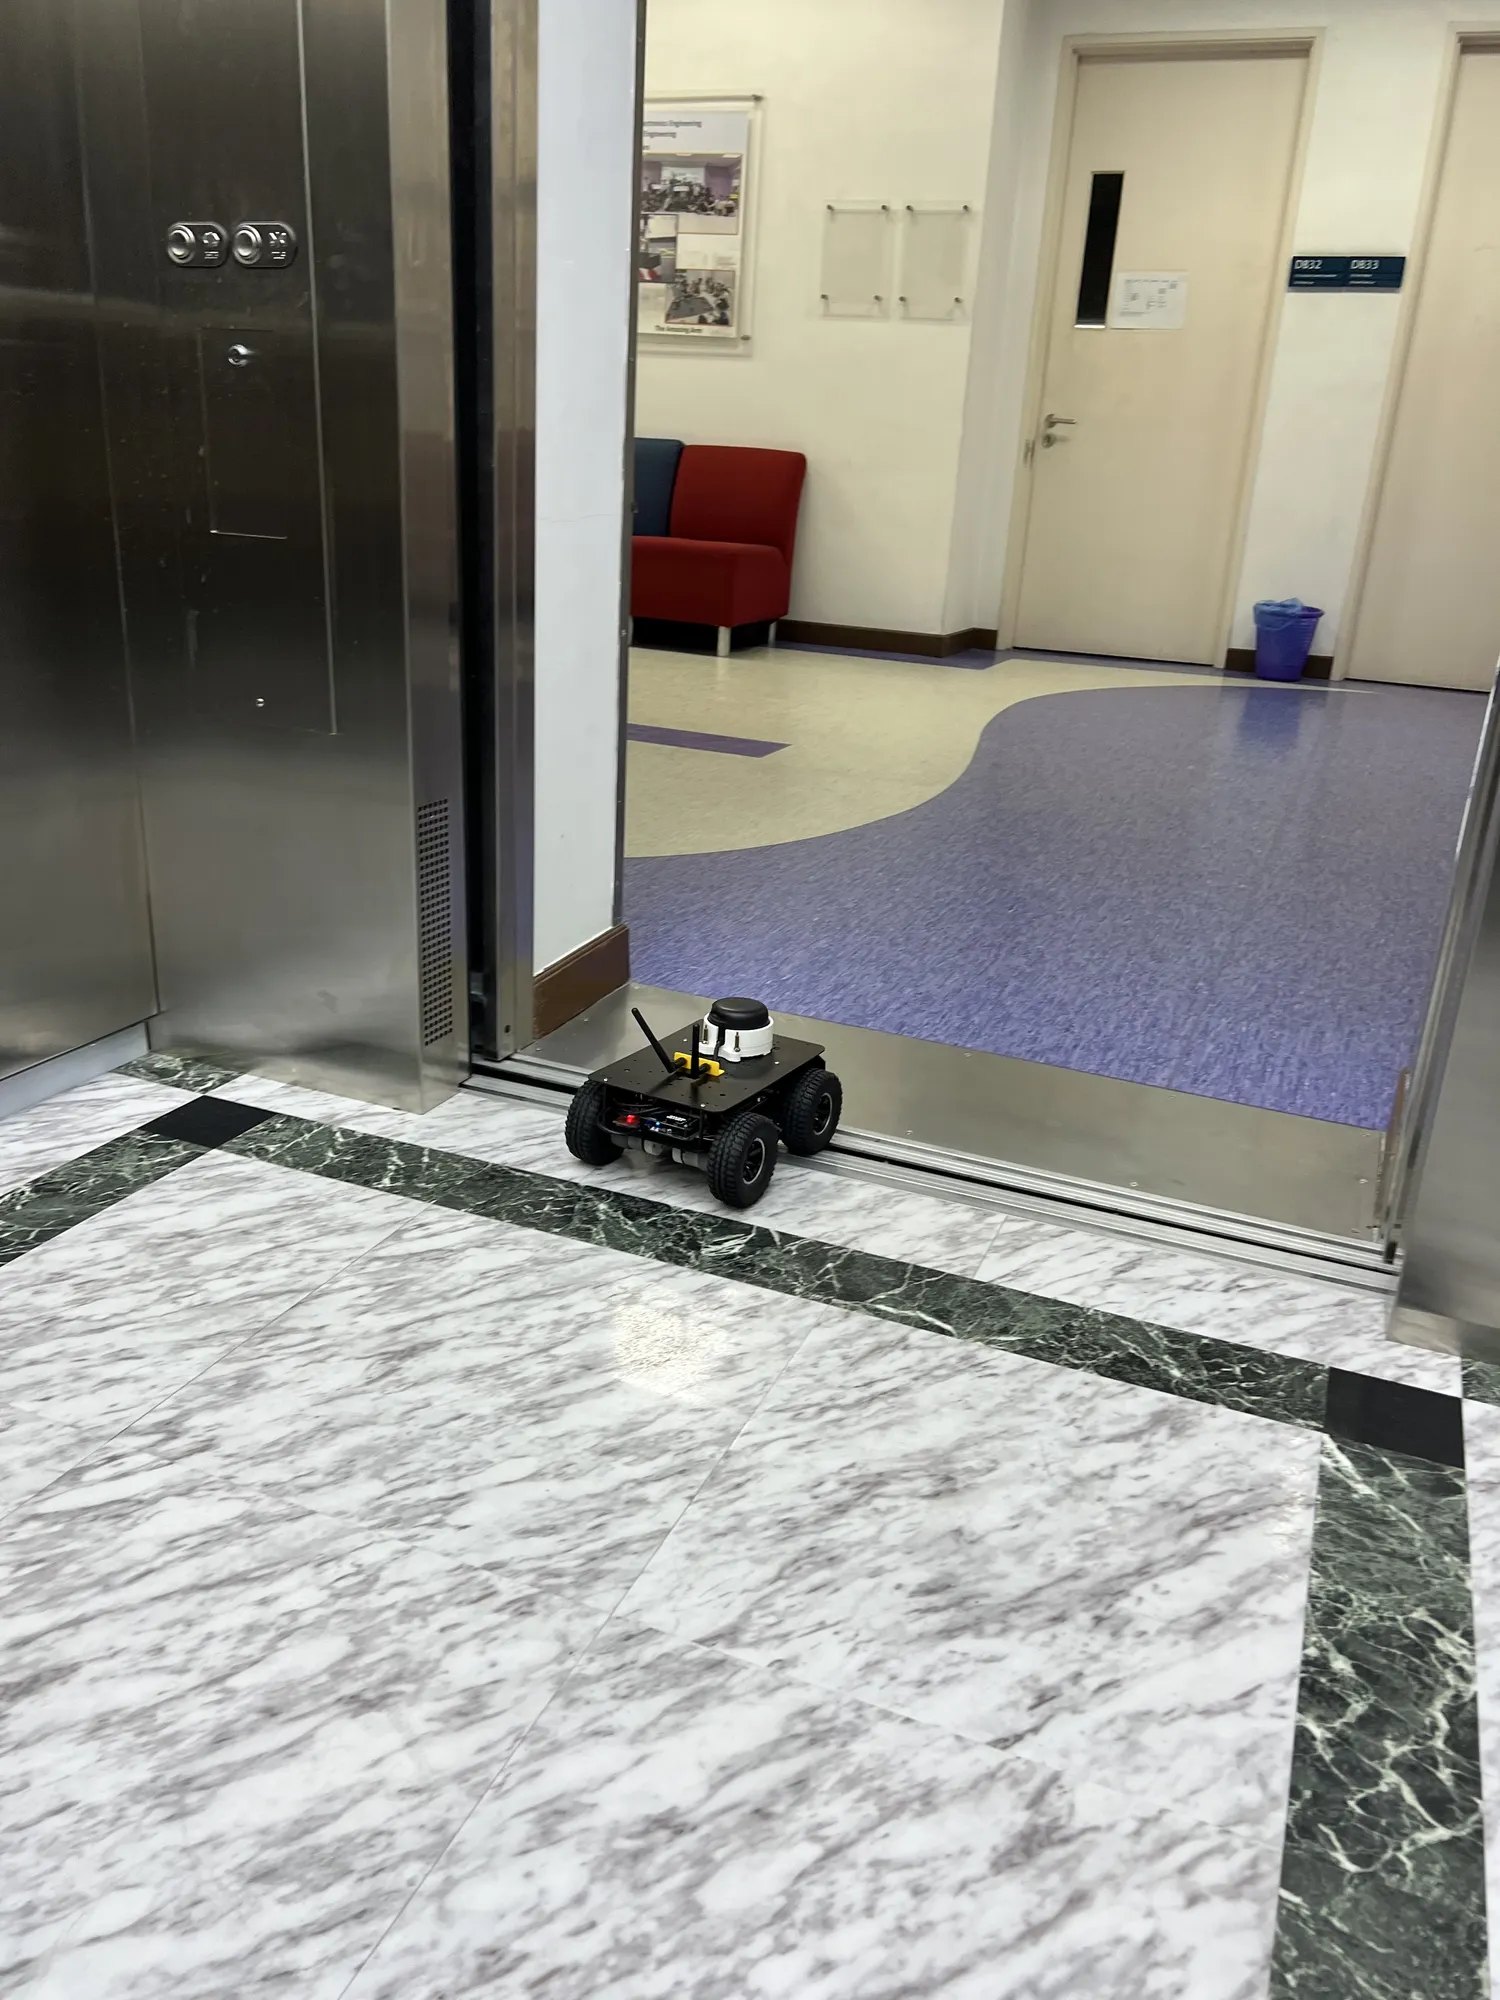
A custom ROS package handles the elevator: getting in, switching maps and continuing on the new floor.
Result
The robot navigated across floors autonomously while avoiding dynamic obstacles. Some manual help was needed only because we had no access to the elevator's API.