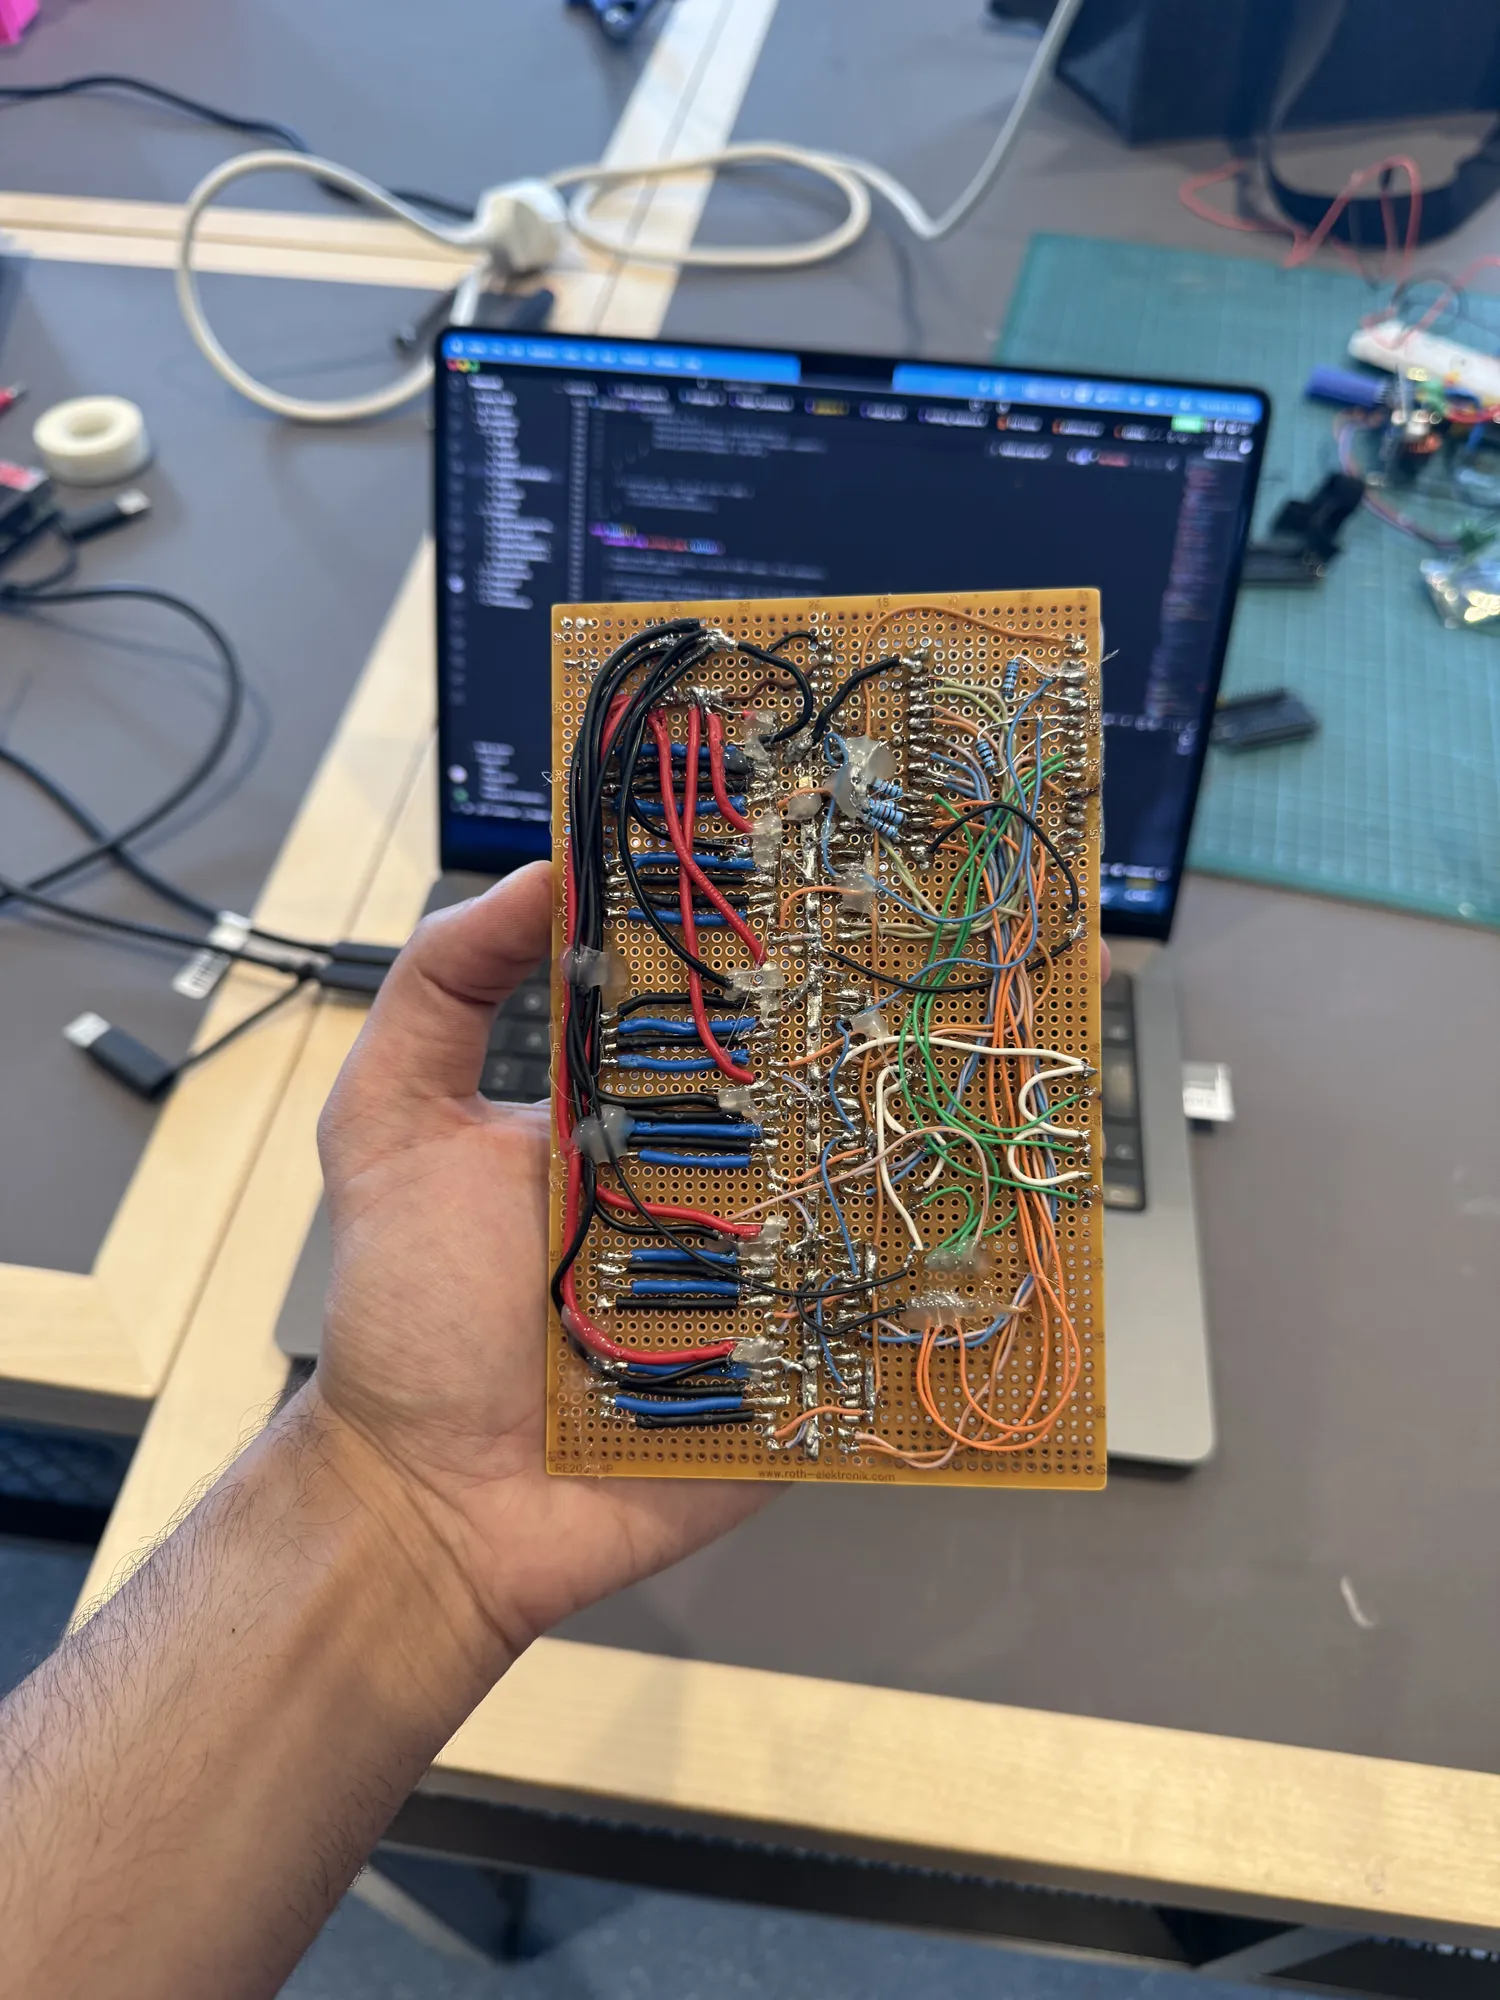
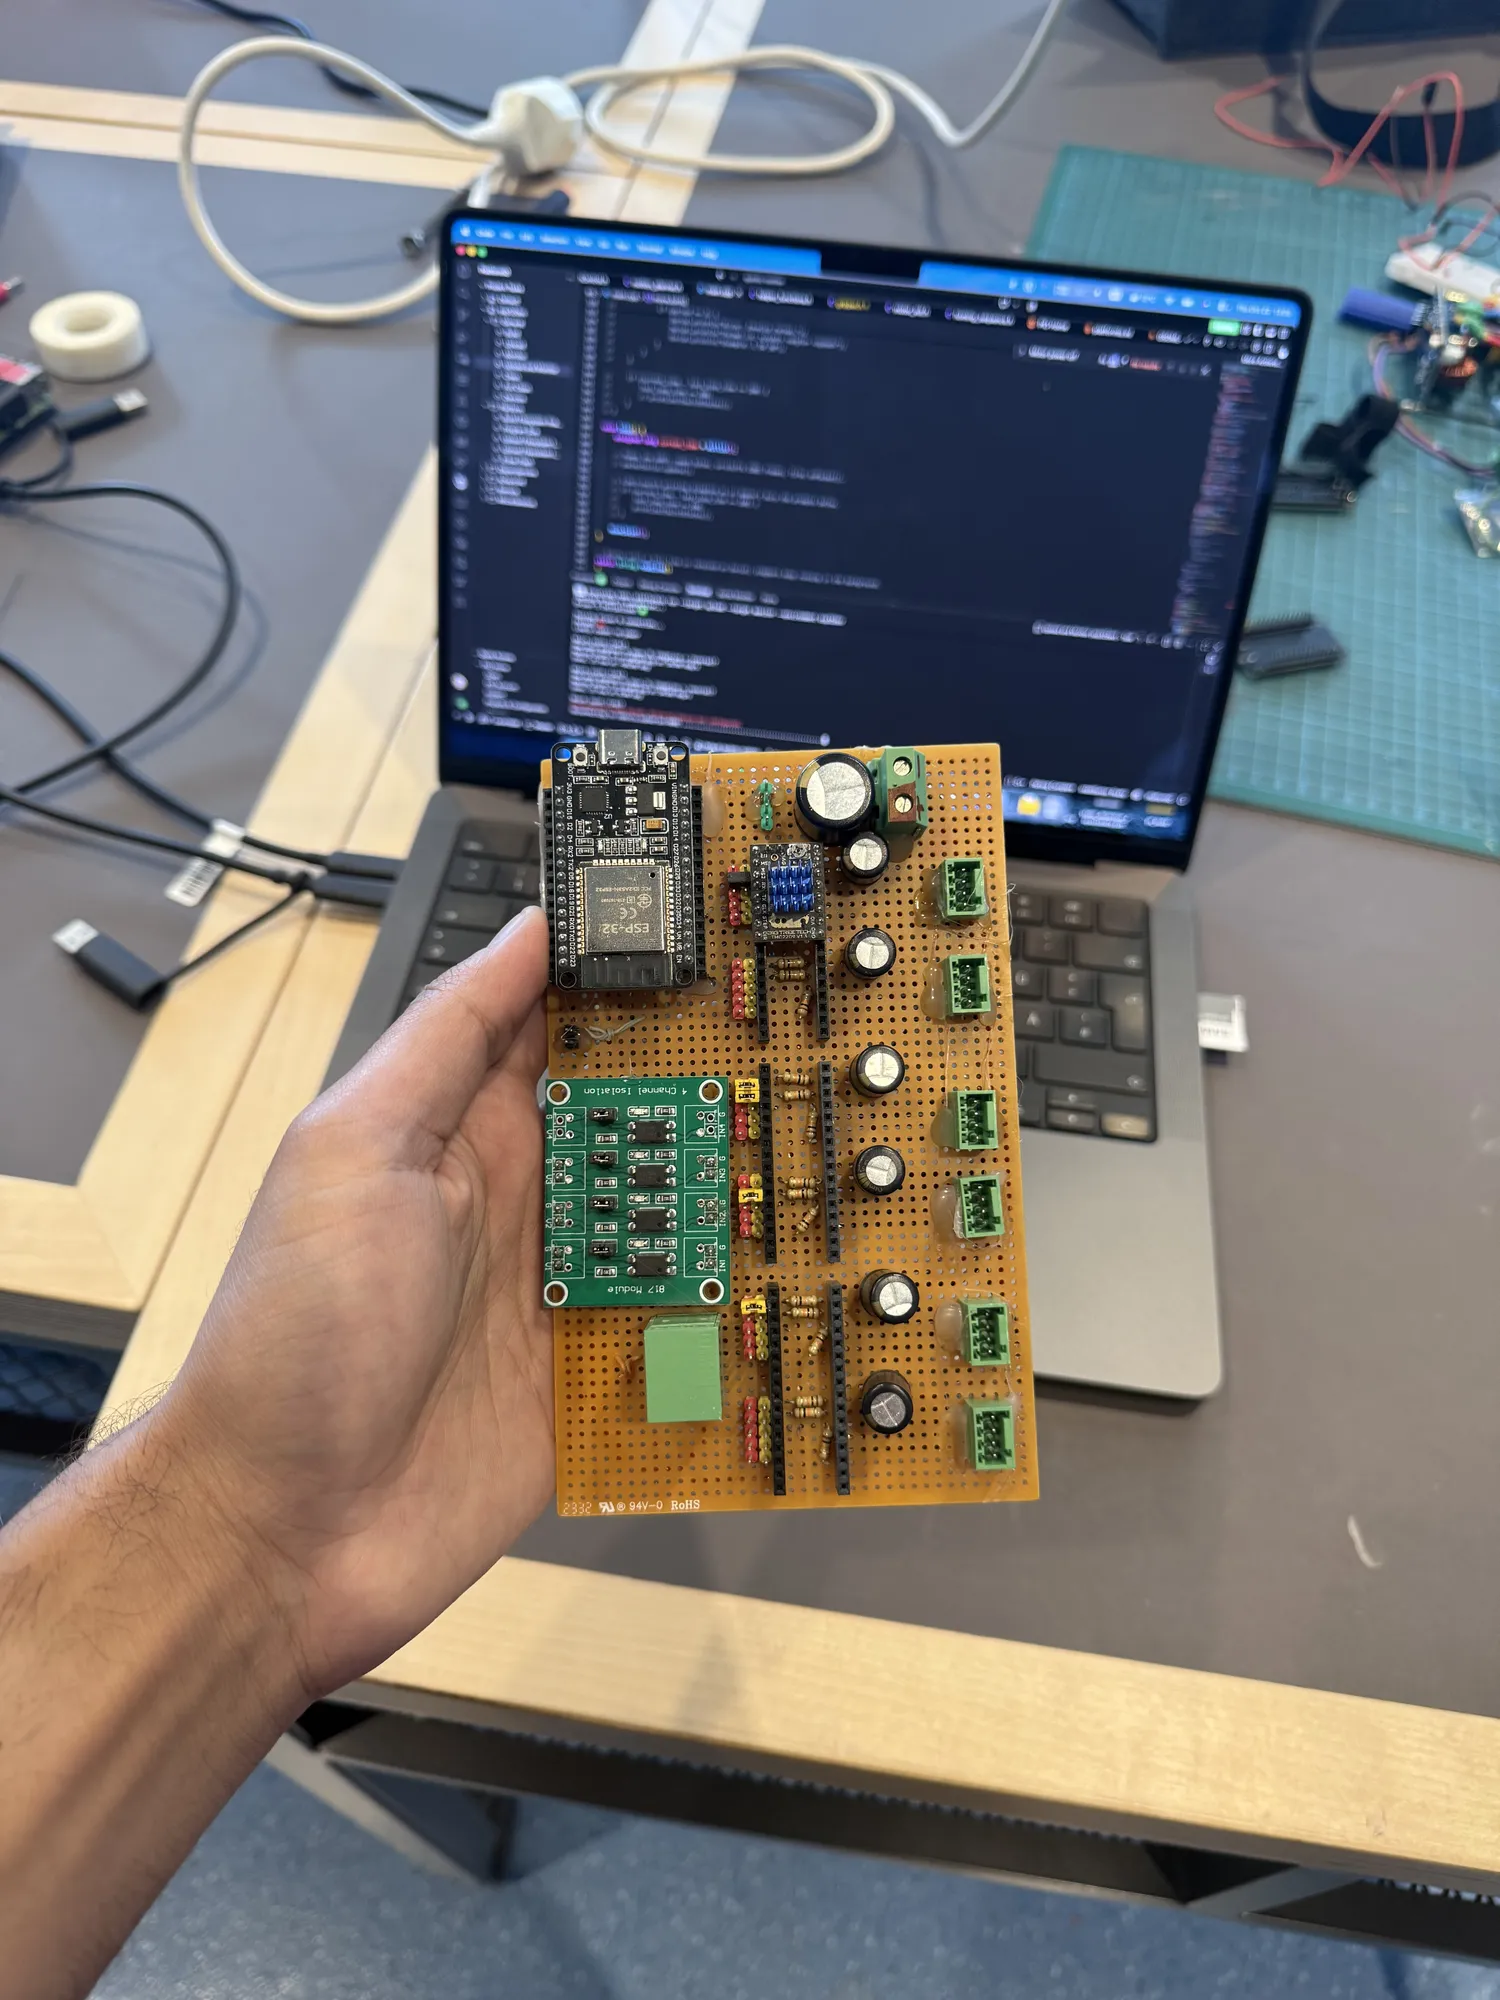
I wanted to really understand the fundamentals of robotics, not just from a textbook but by implementing them myself. So I took the open-source PAROL6 arm and built everything around it from scratch: the electronics, the firmware and the whole software stack.
Electronics on the bench
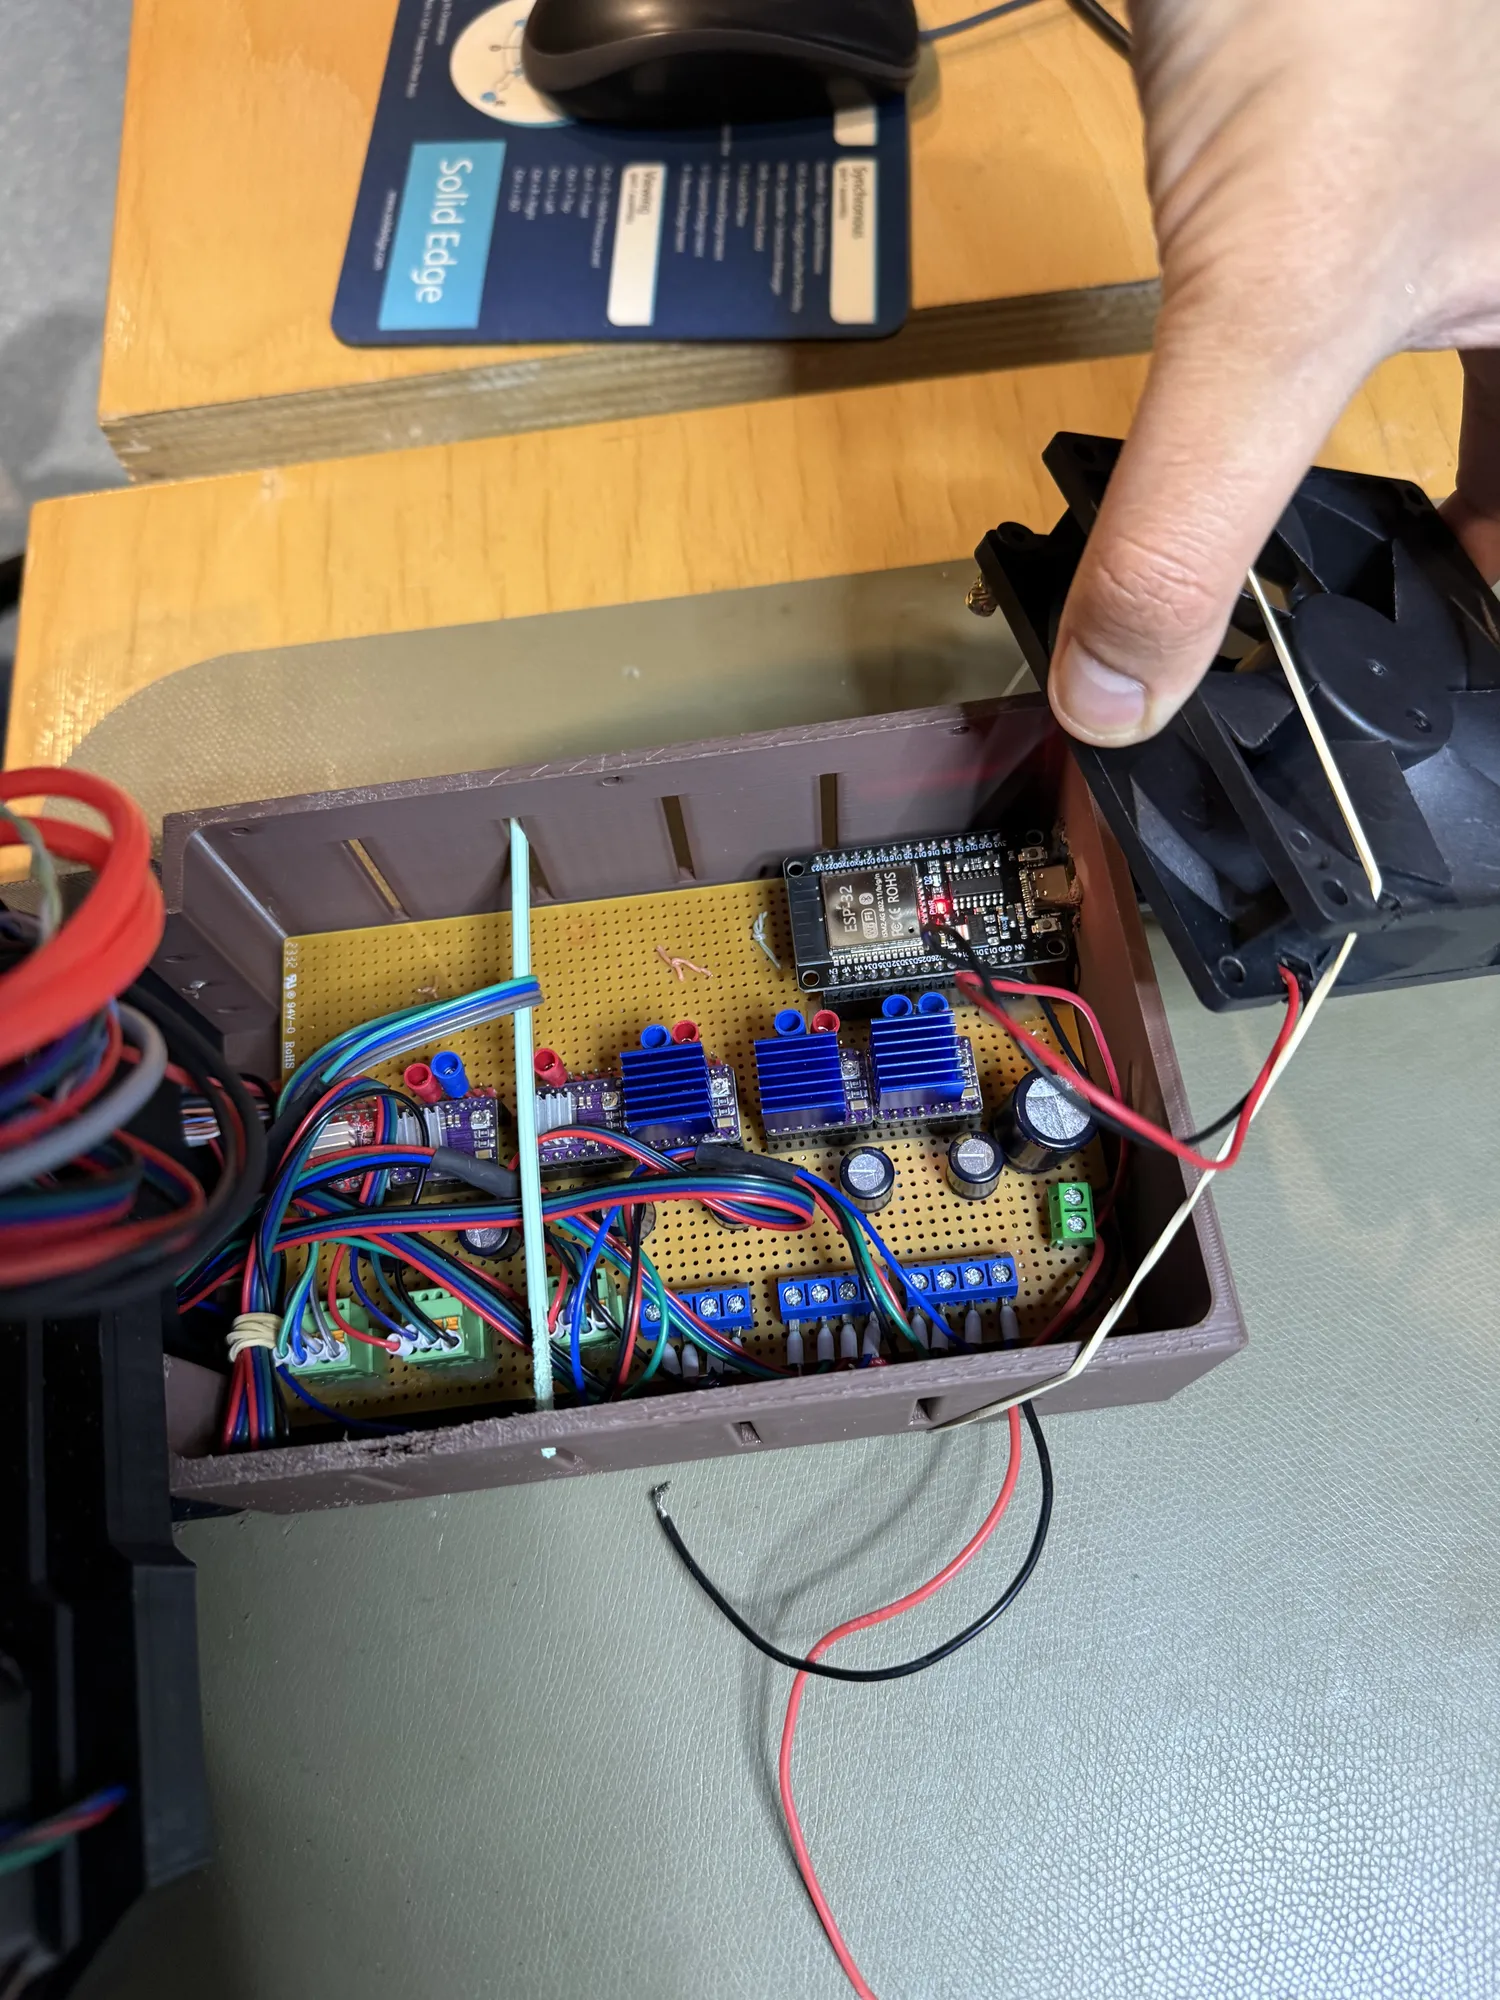
Before any link moved, every driver and joint was tested on the desk.
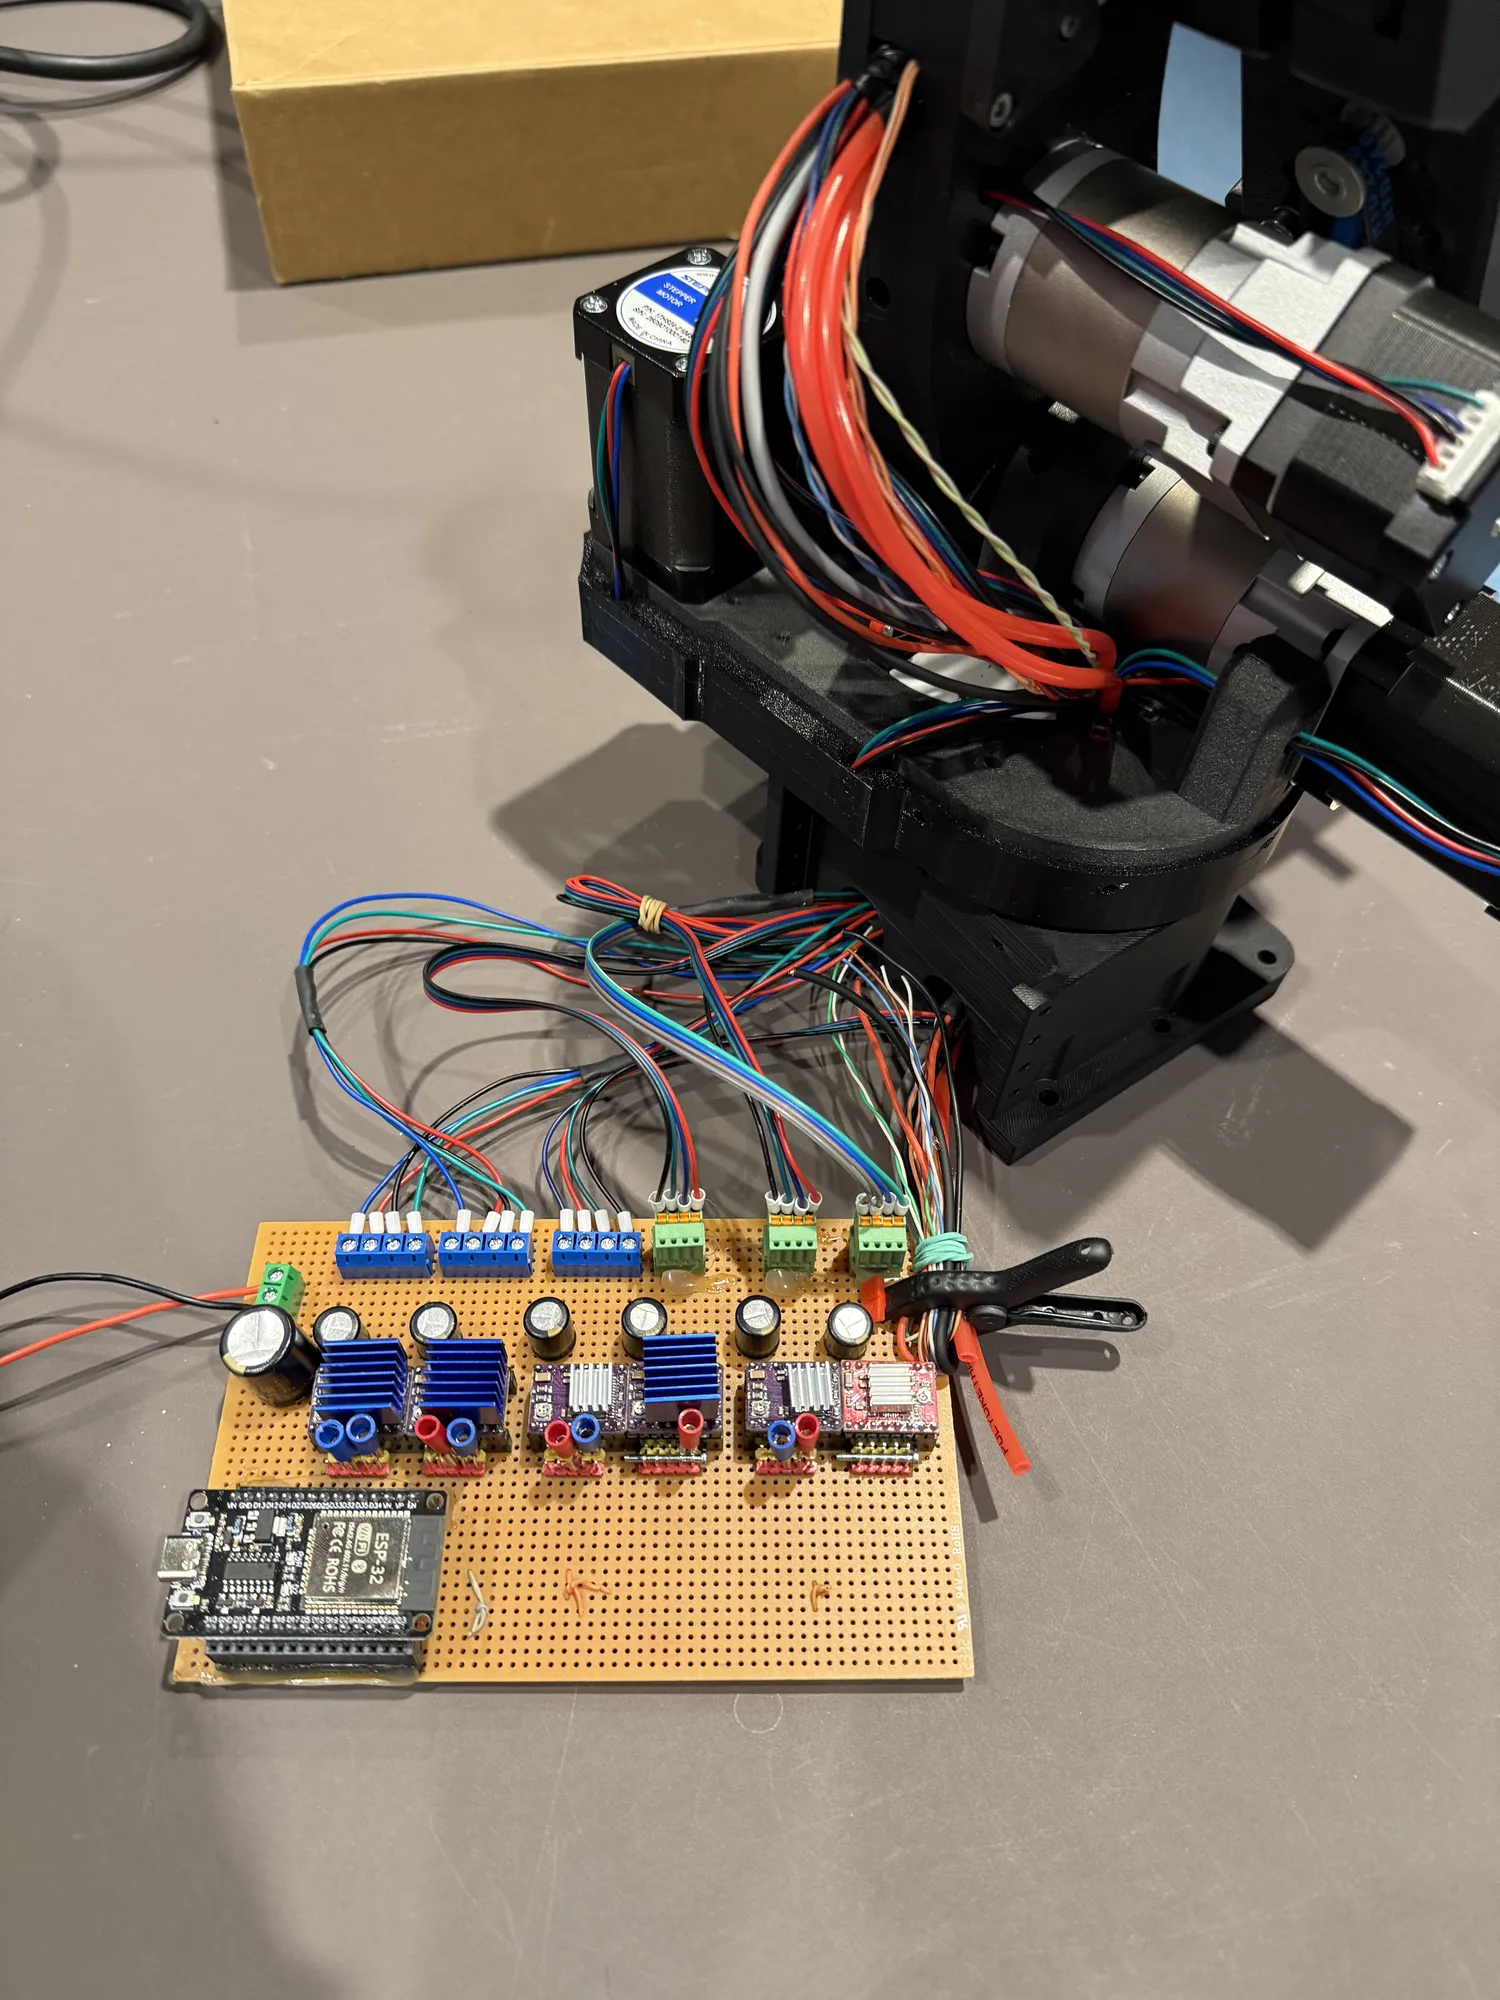
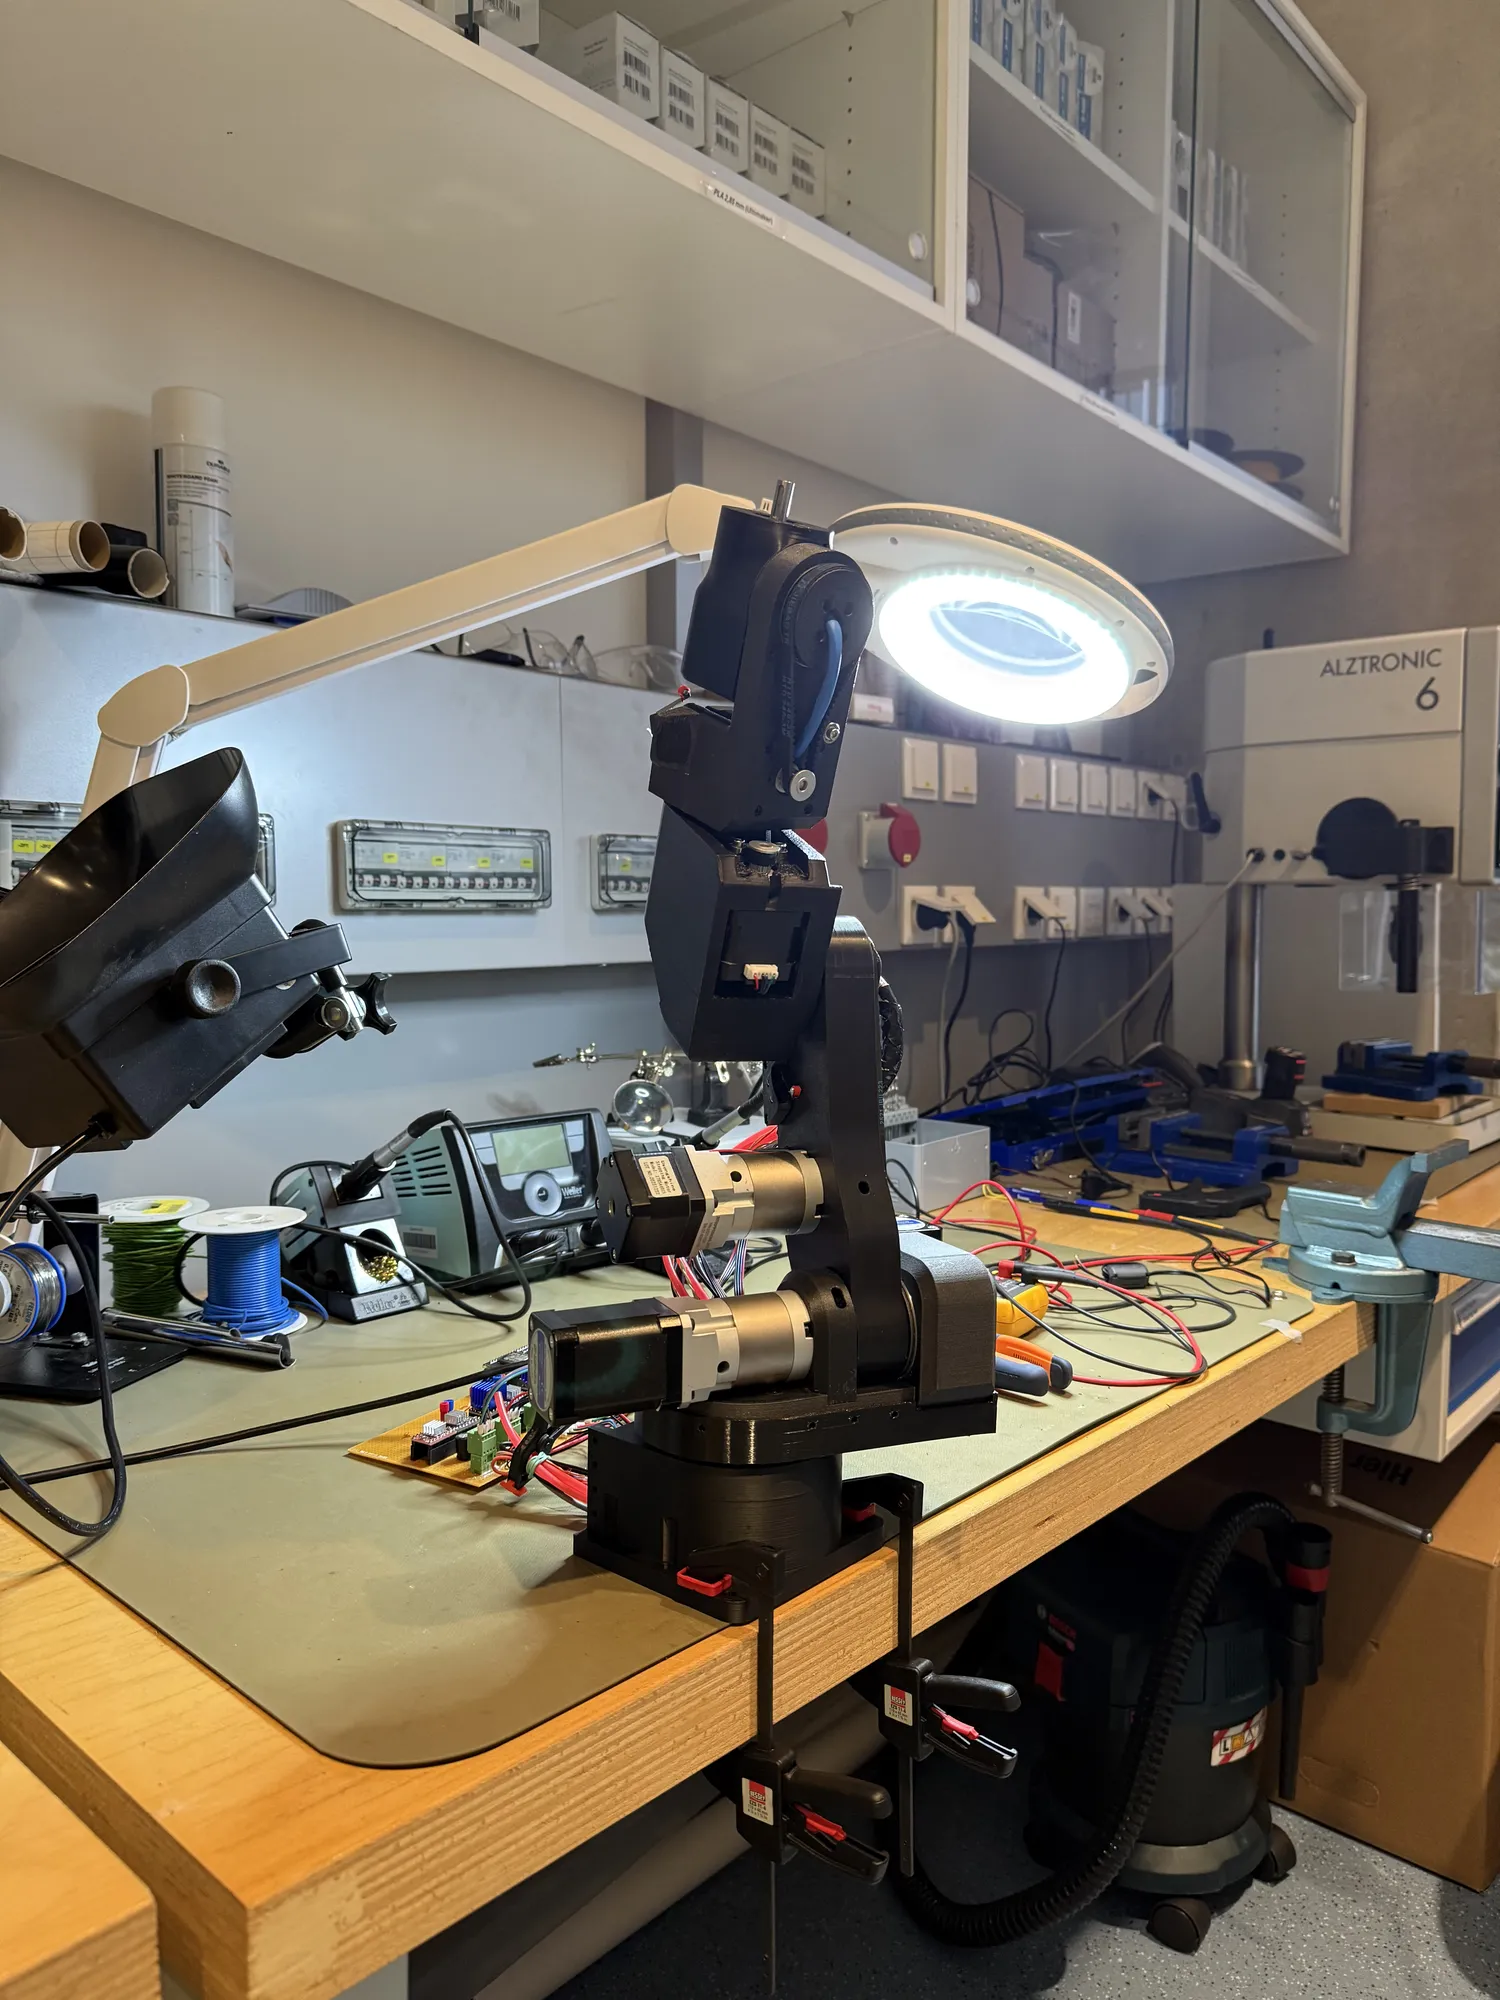
A detour into inverse kinematics
Halfway through, I built a small 2-DOF planar arm to test basic inverse kinematics before trusting it on six joints.
First motion
Real arm and simulation in sync
Learning-based control
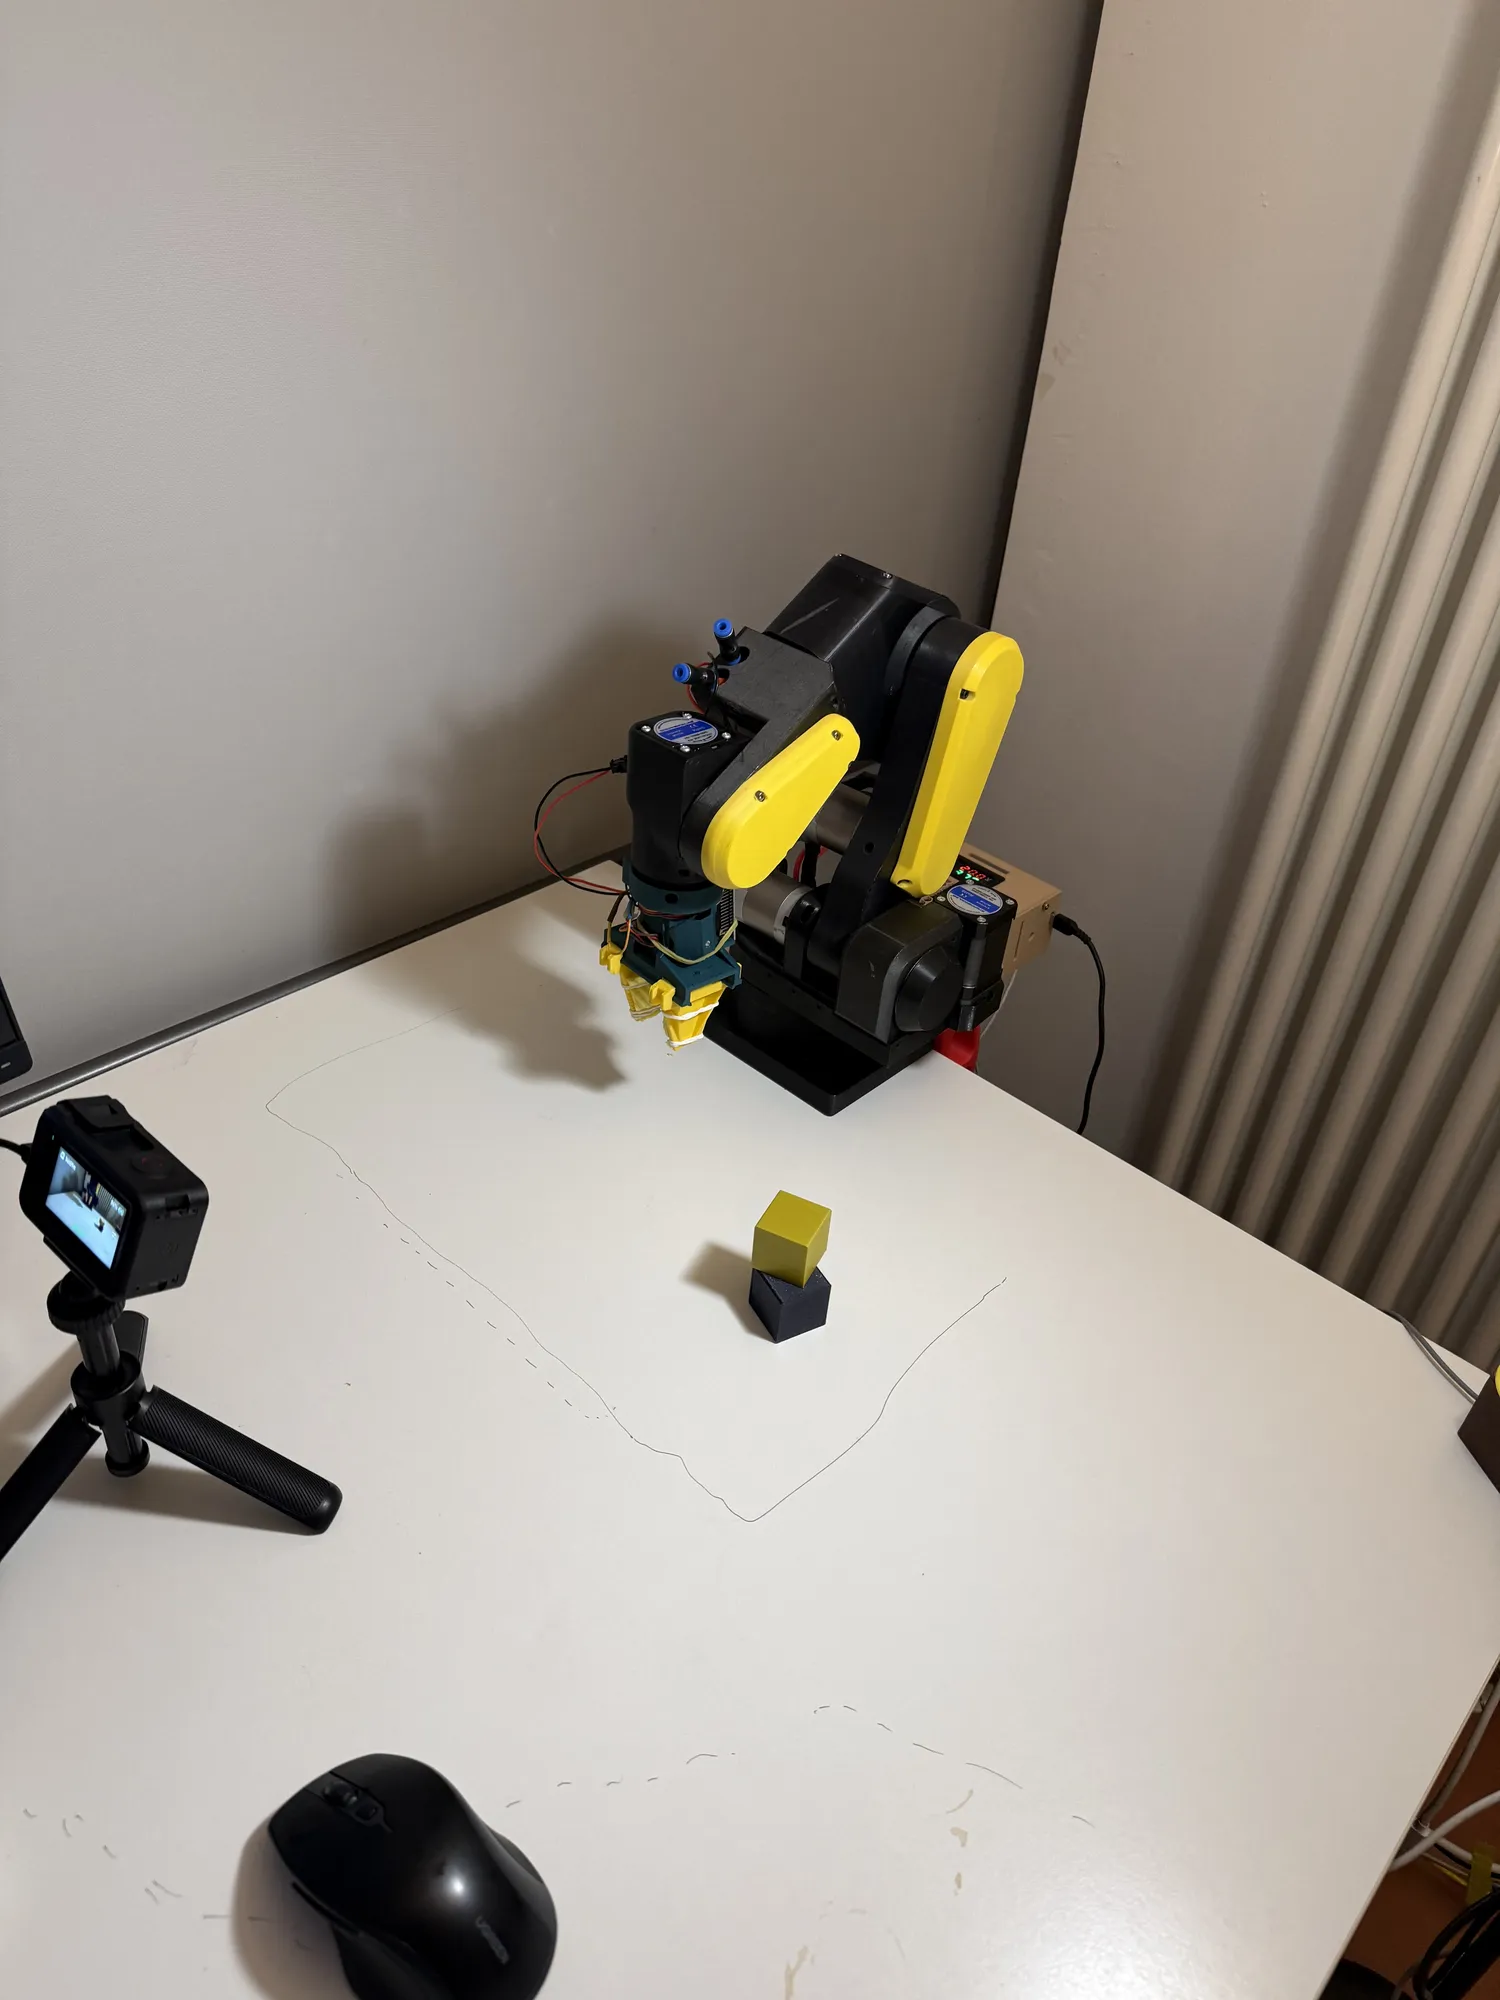
The next step was learning. I collected demonstrations and fine-tuned π0, a vision-language-action model. Success rates are not great yet, mostly because of too much variation in my dataset, which is what I'm working on now.
Custom PCB
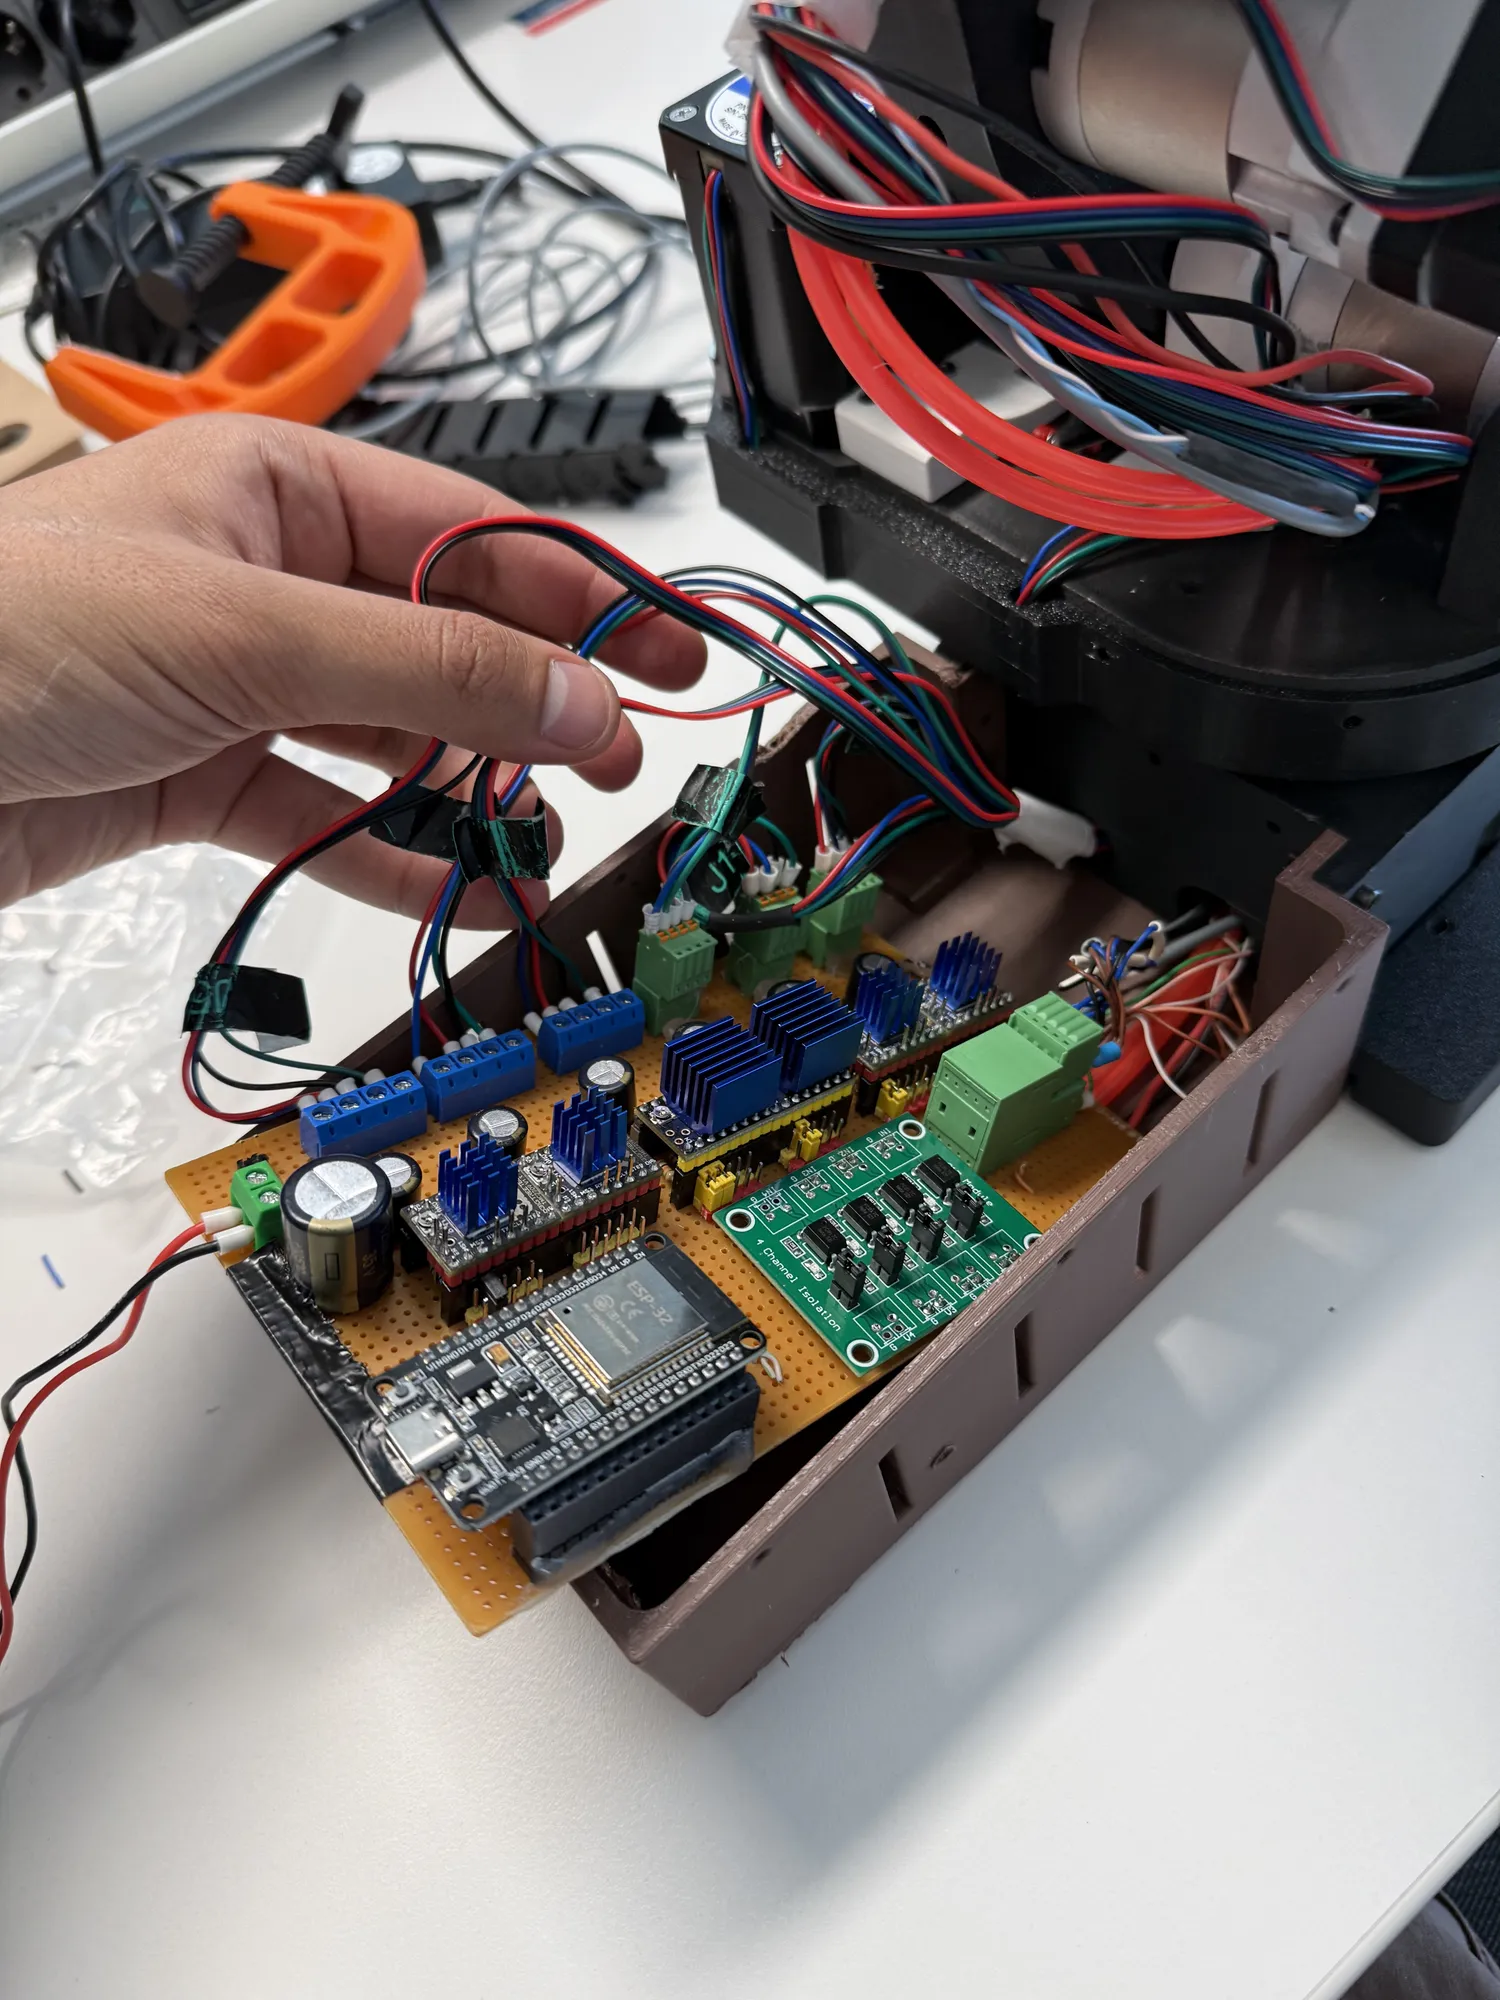
The breadboard-era wiring is being replaced by a custom board.