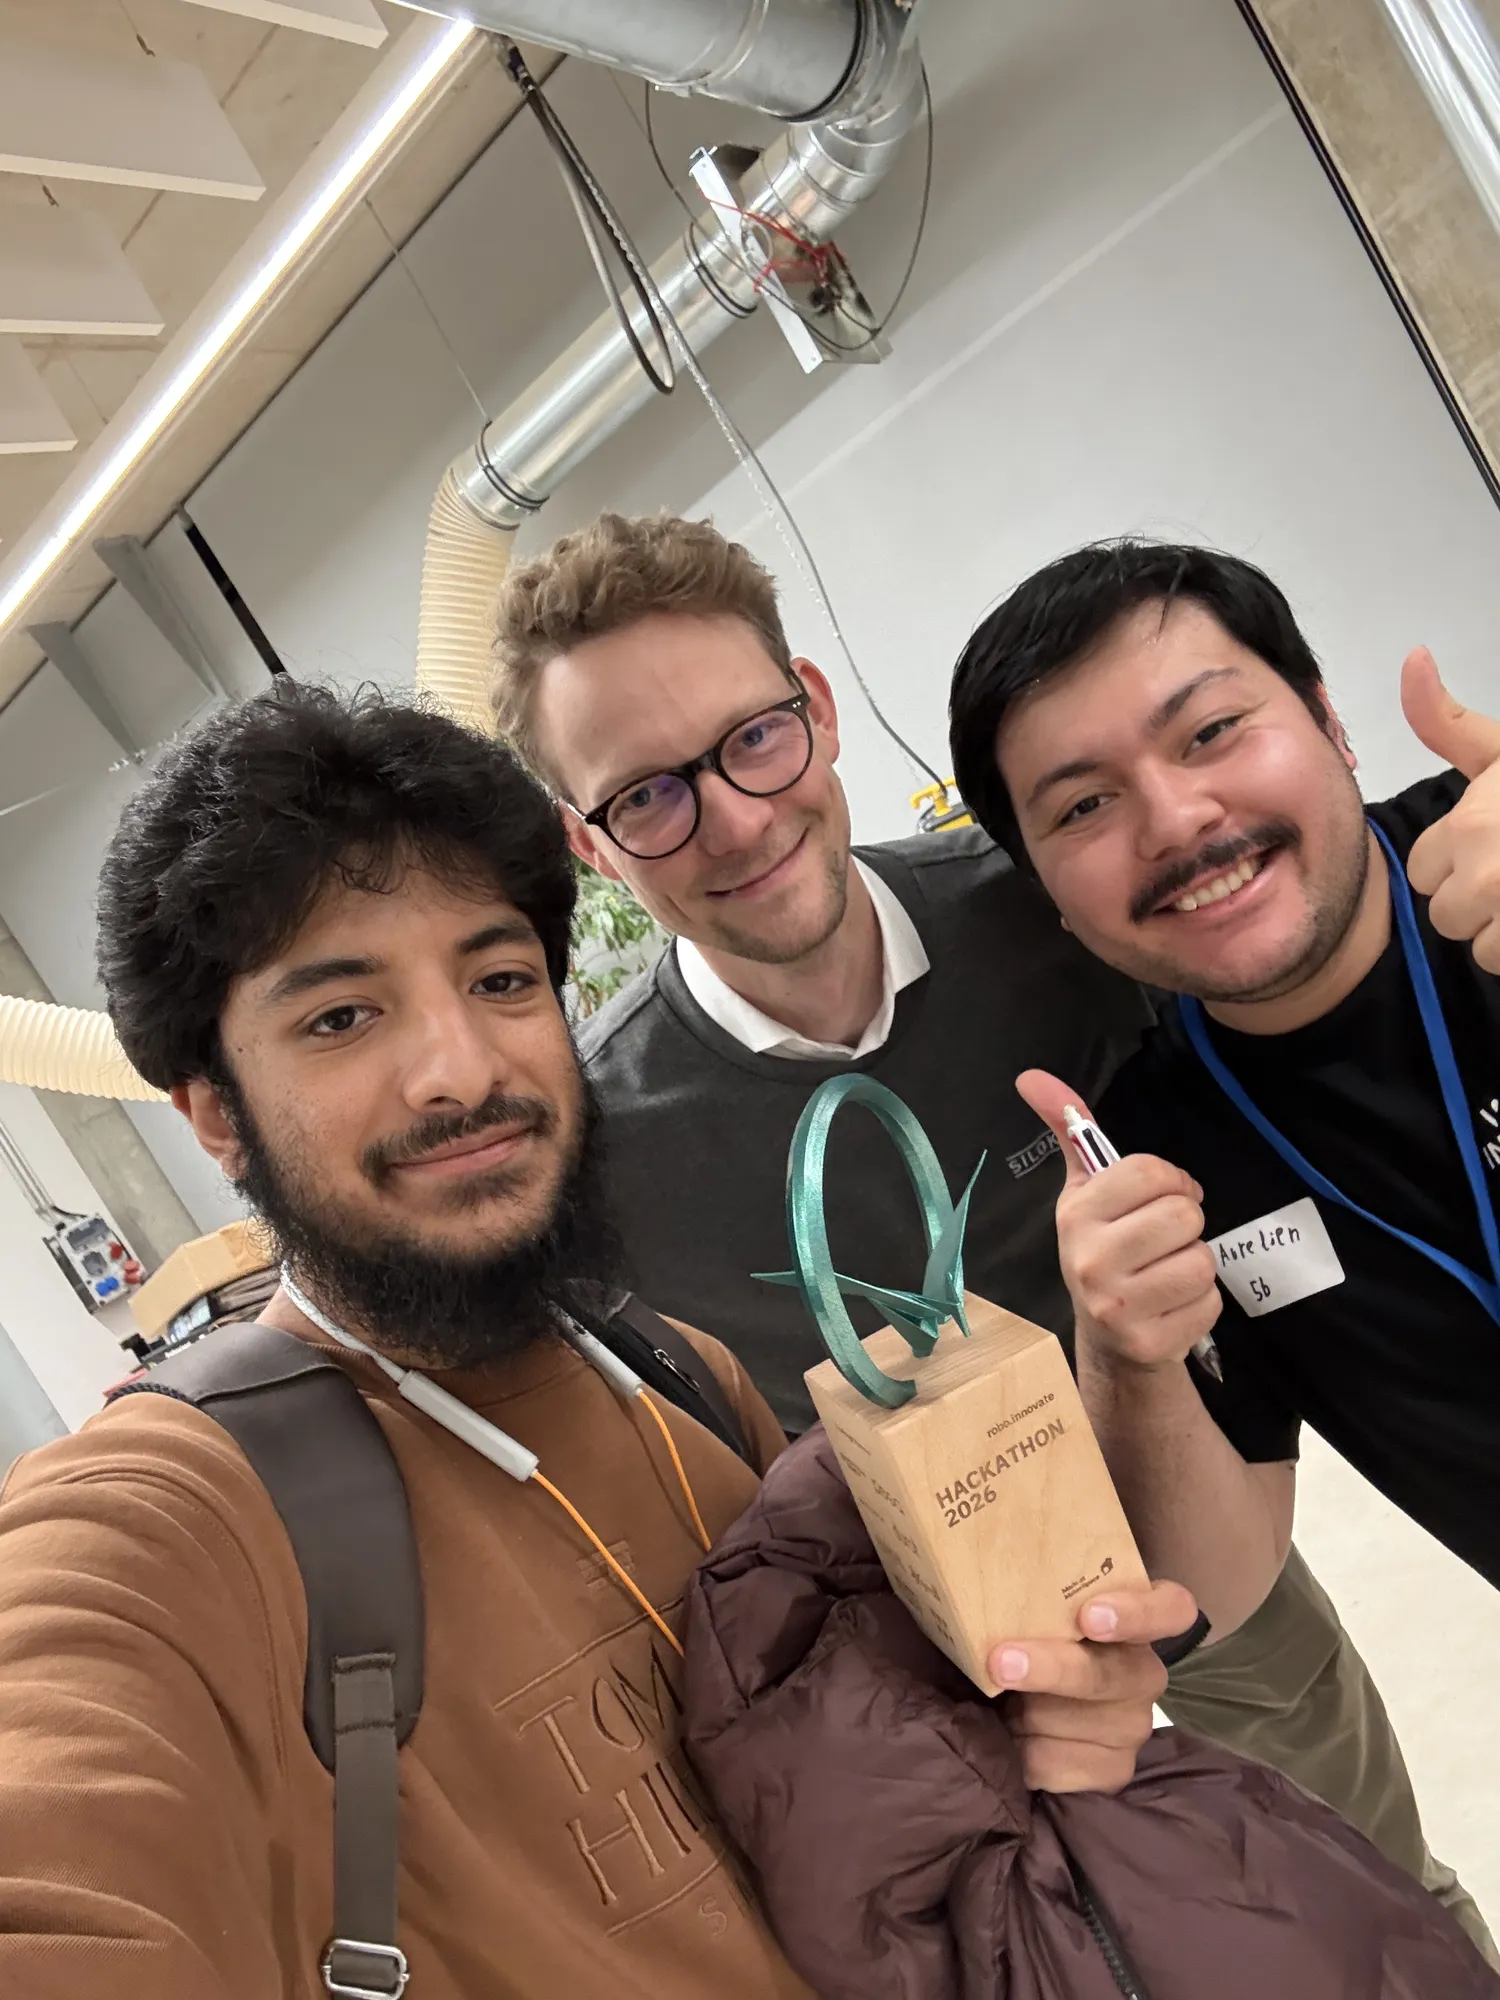
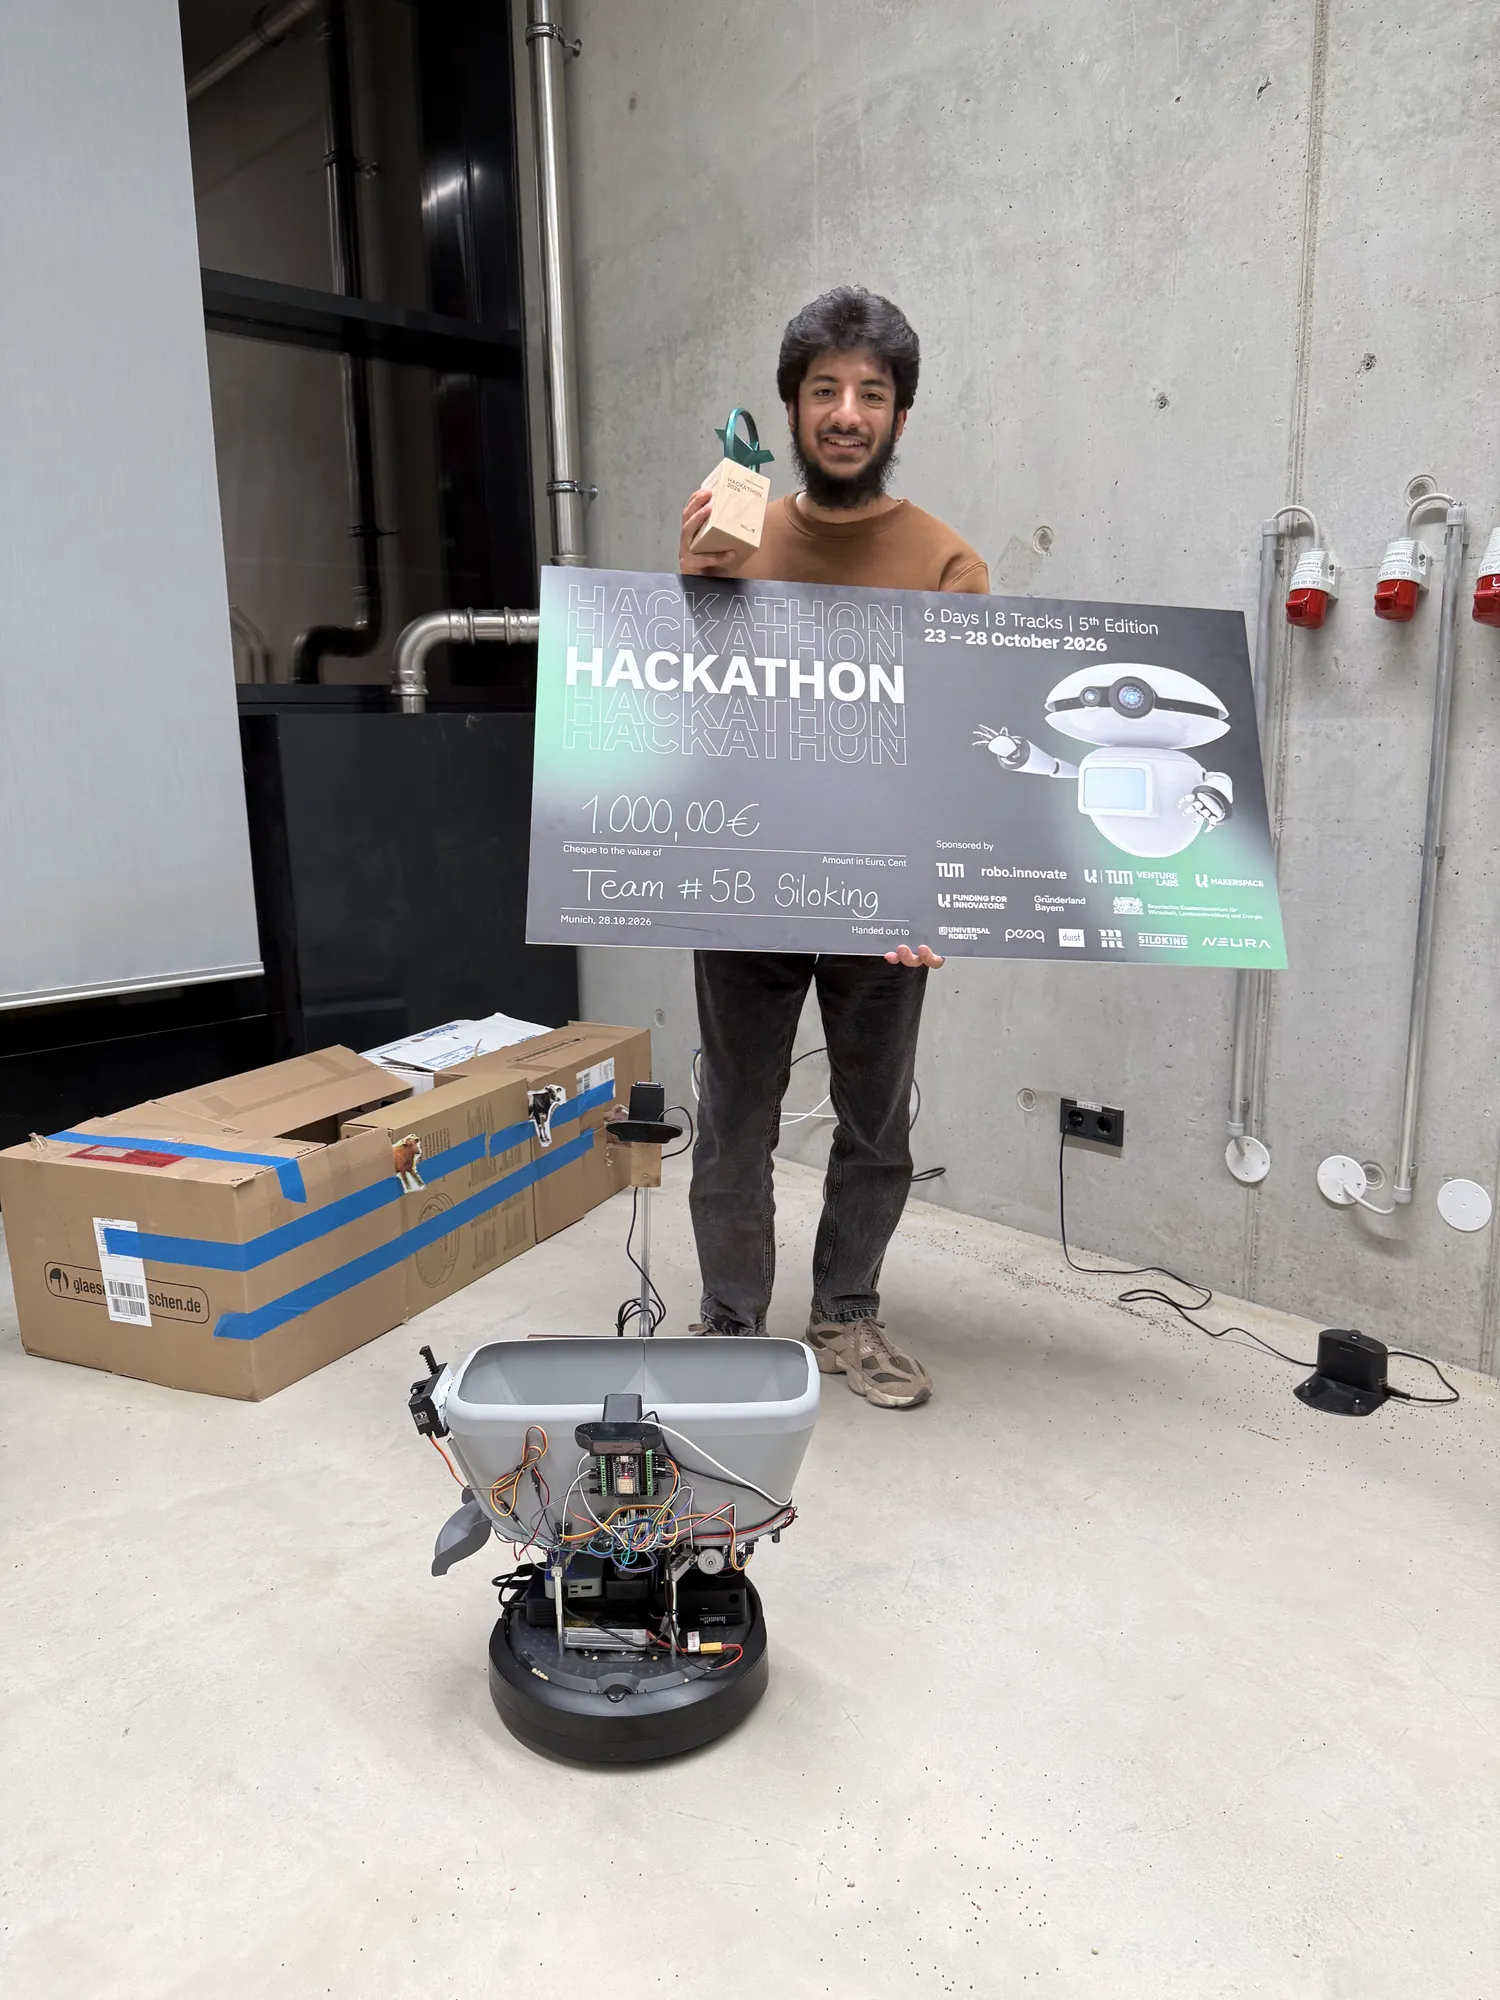
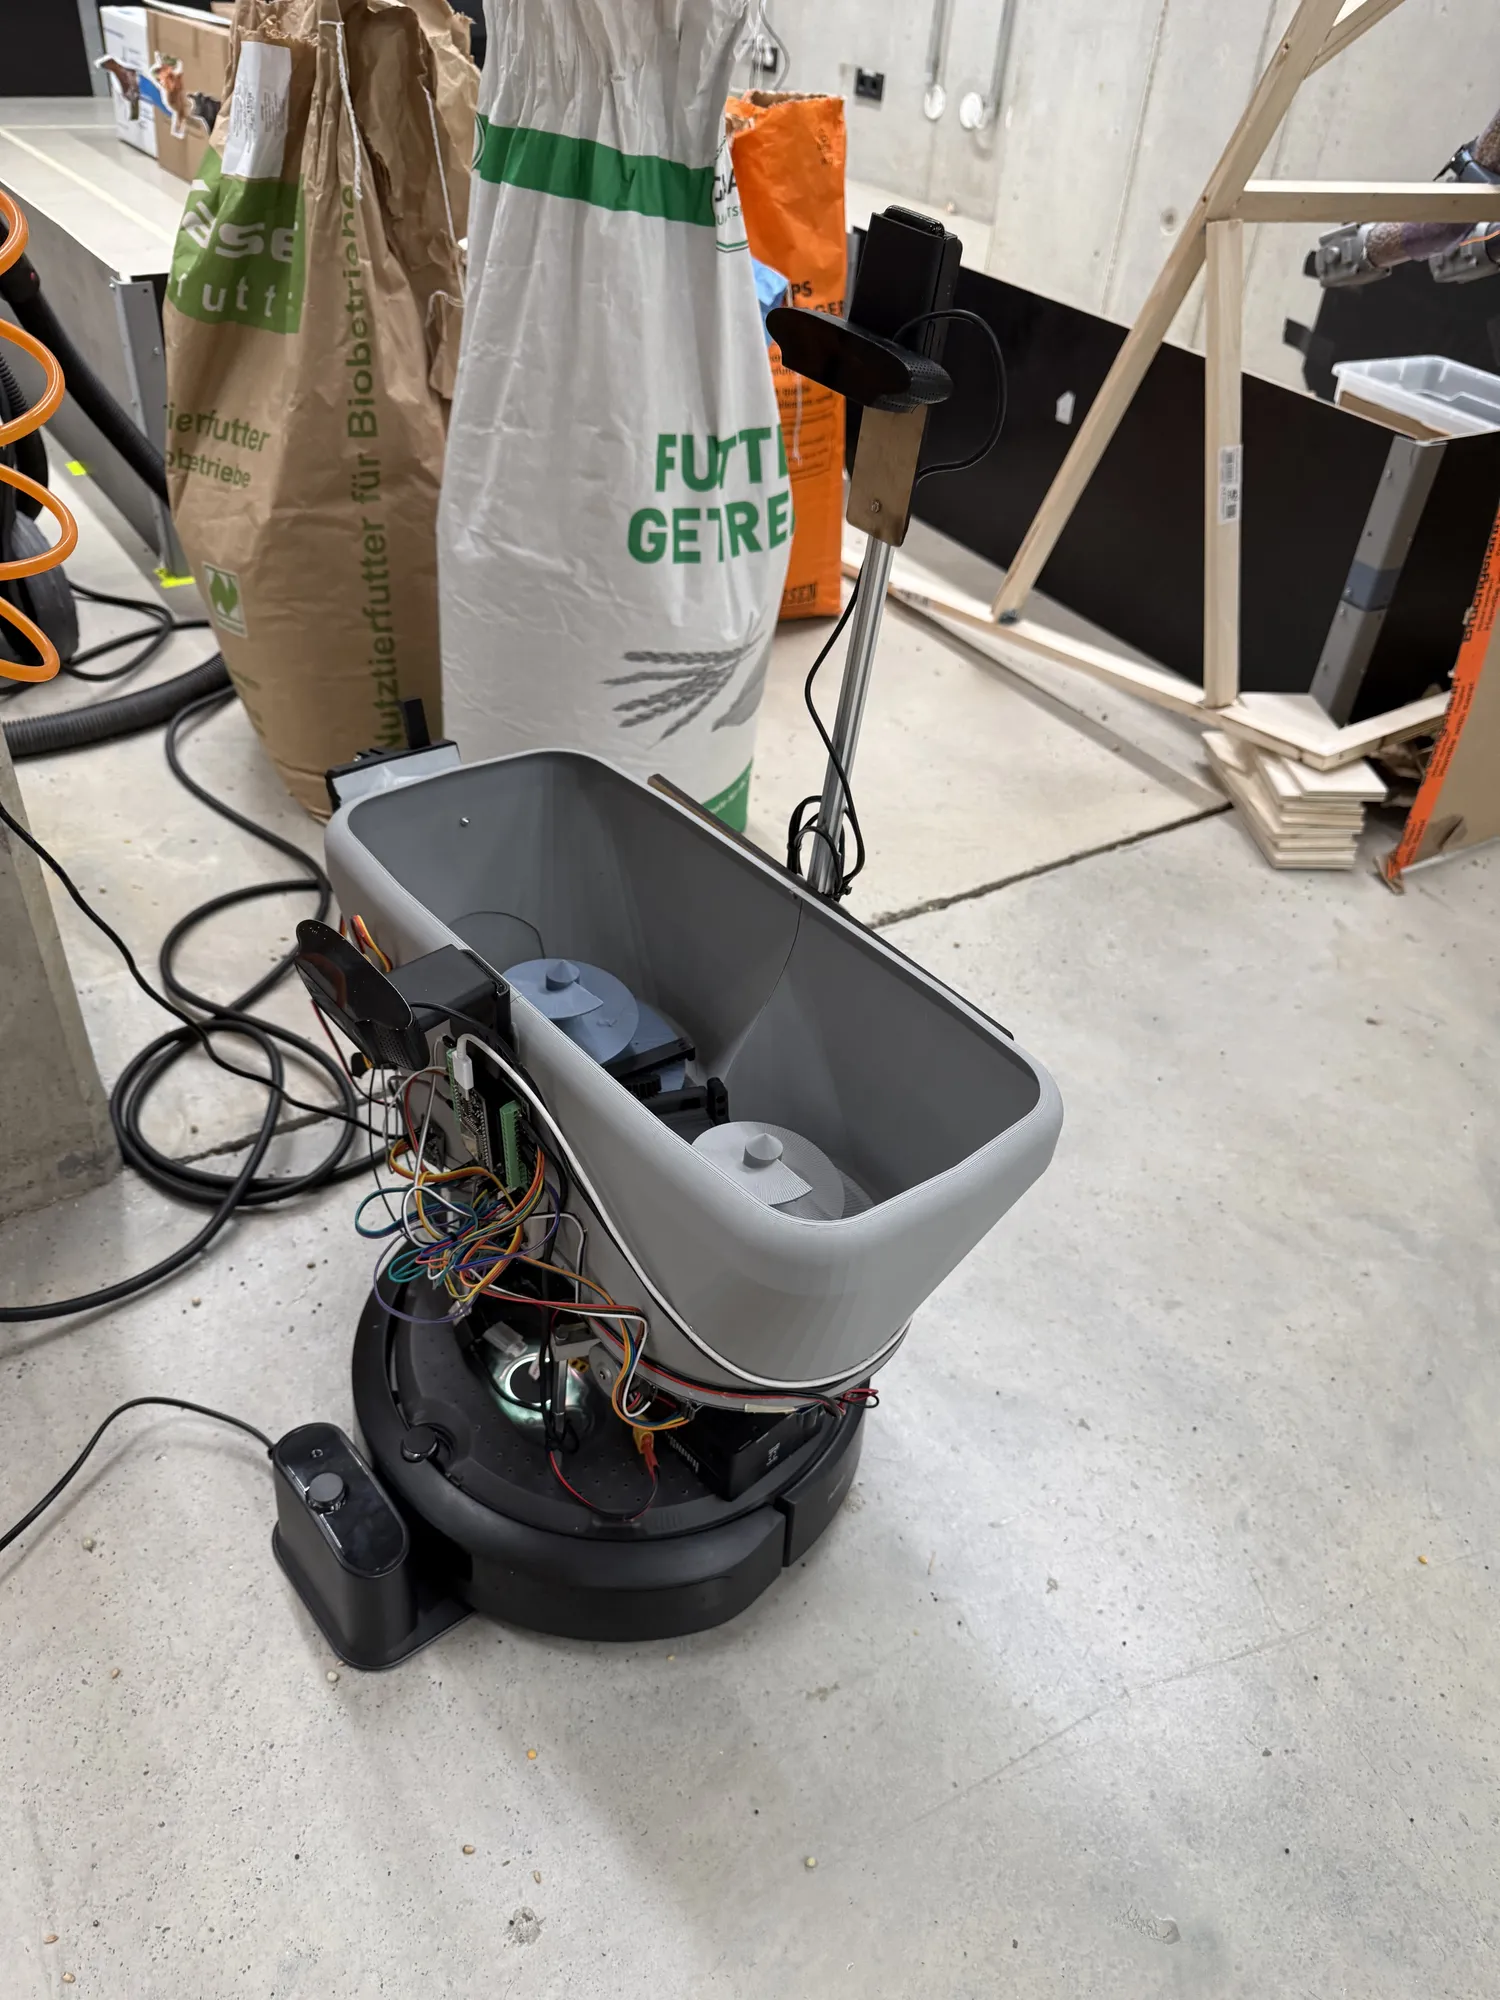
We were given a mobile base that accepts ROS topics and a feed container from Silo King, the challenge partner. The task: build a completely autonomous feeding stack.
The mission
- Undock from the charging station.
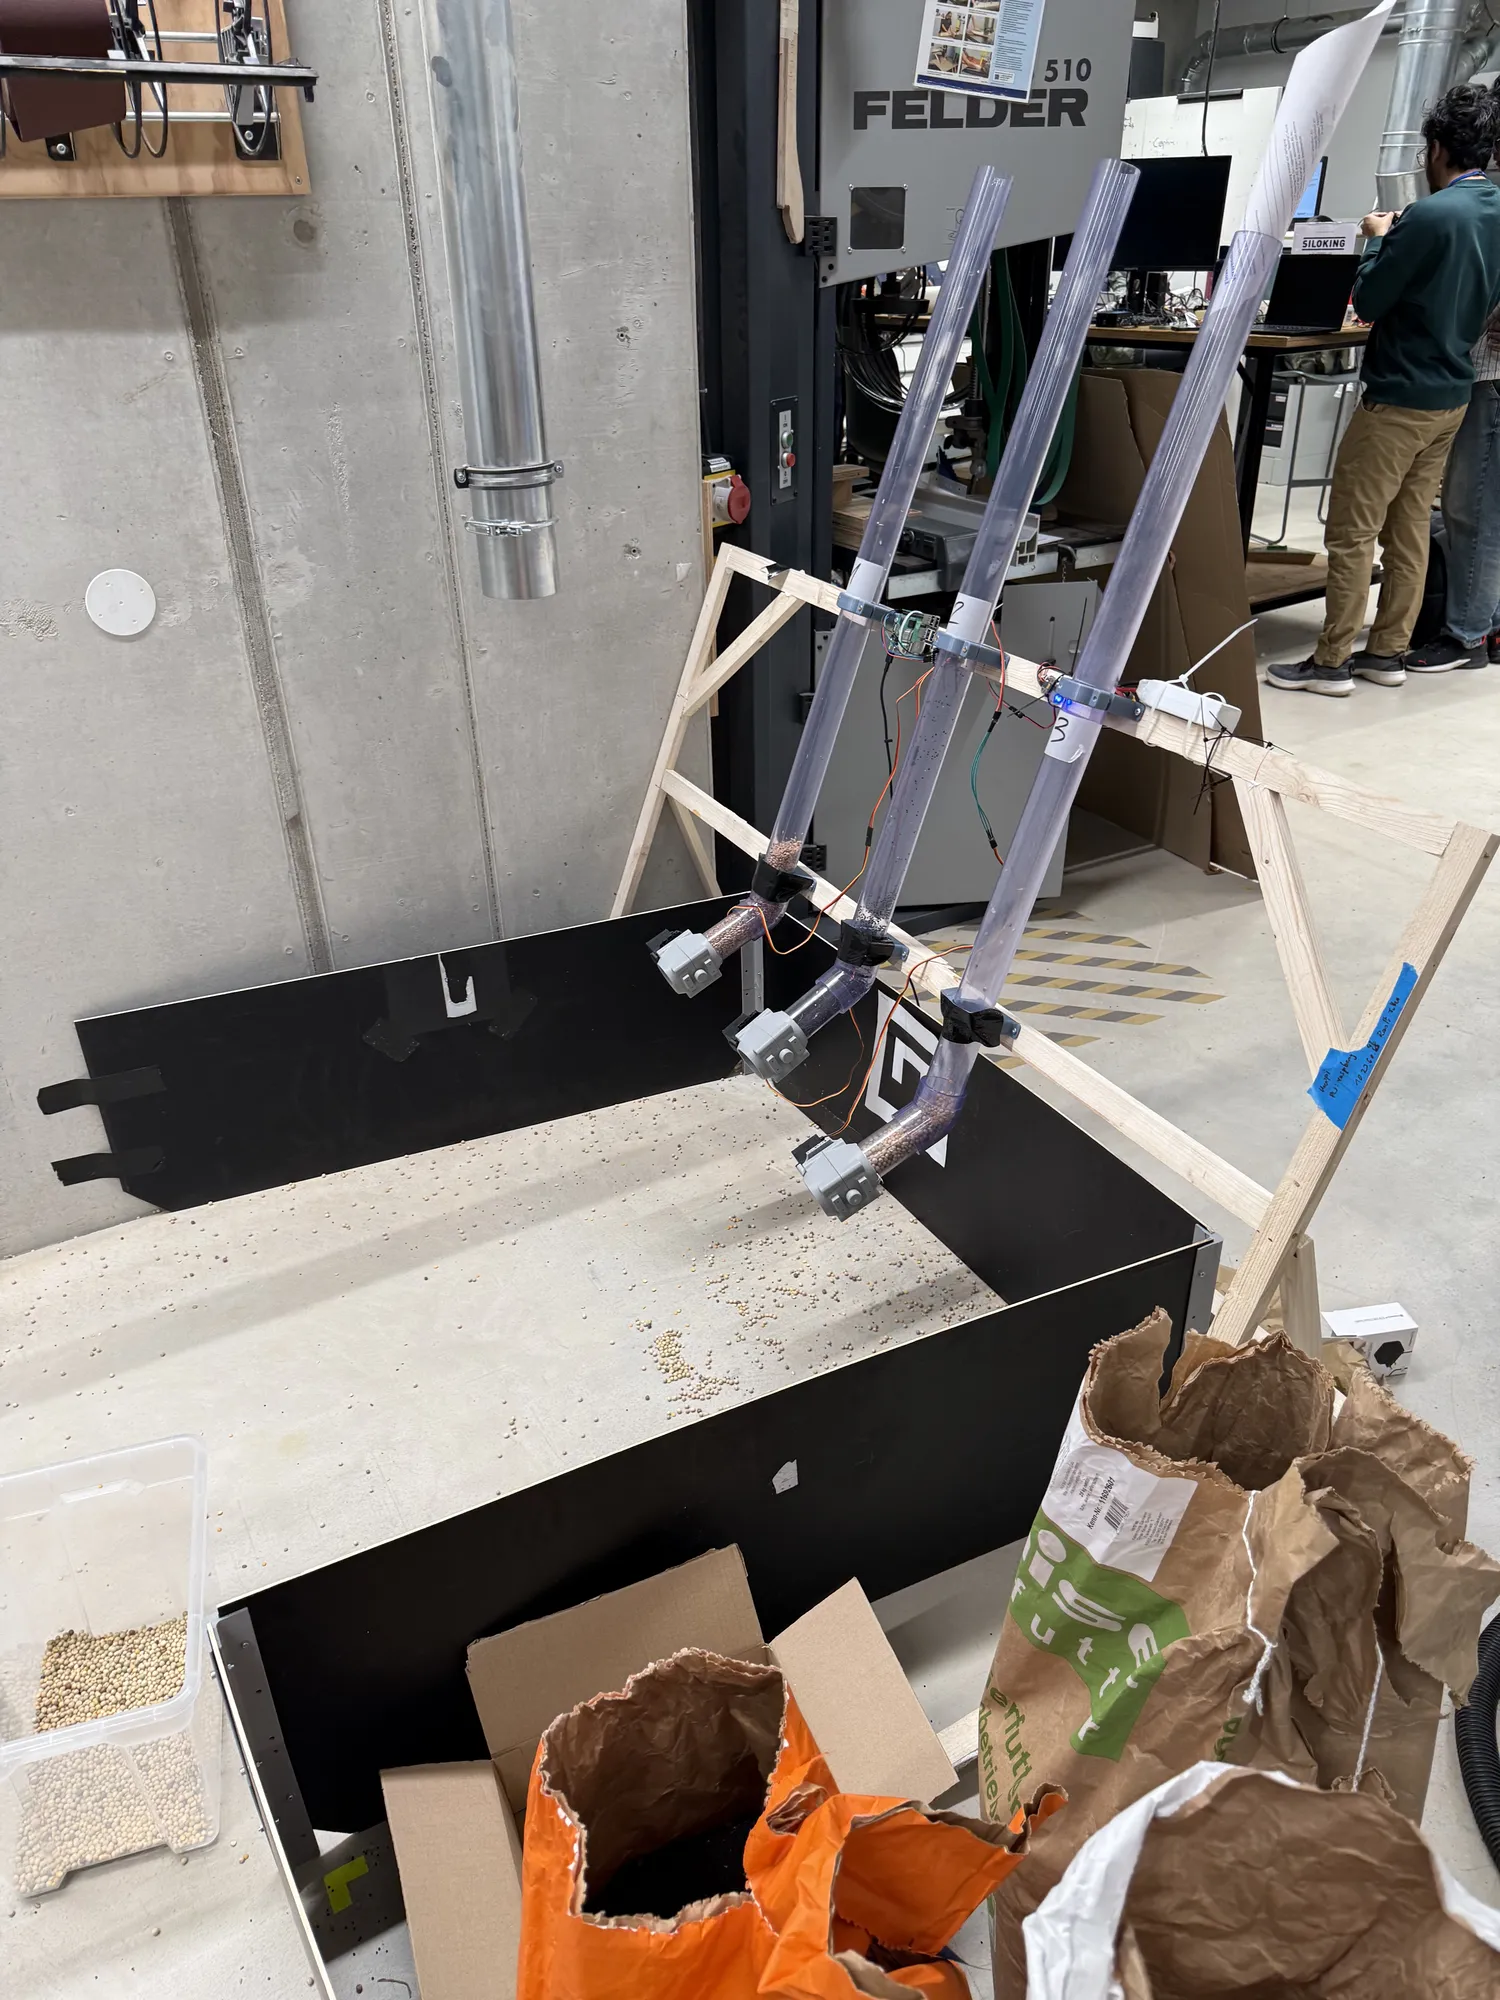
- Collect three feed components by weight in a 40 / 20 / 40 ratio, measured with load cells.
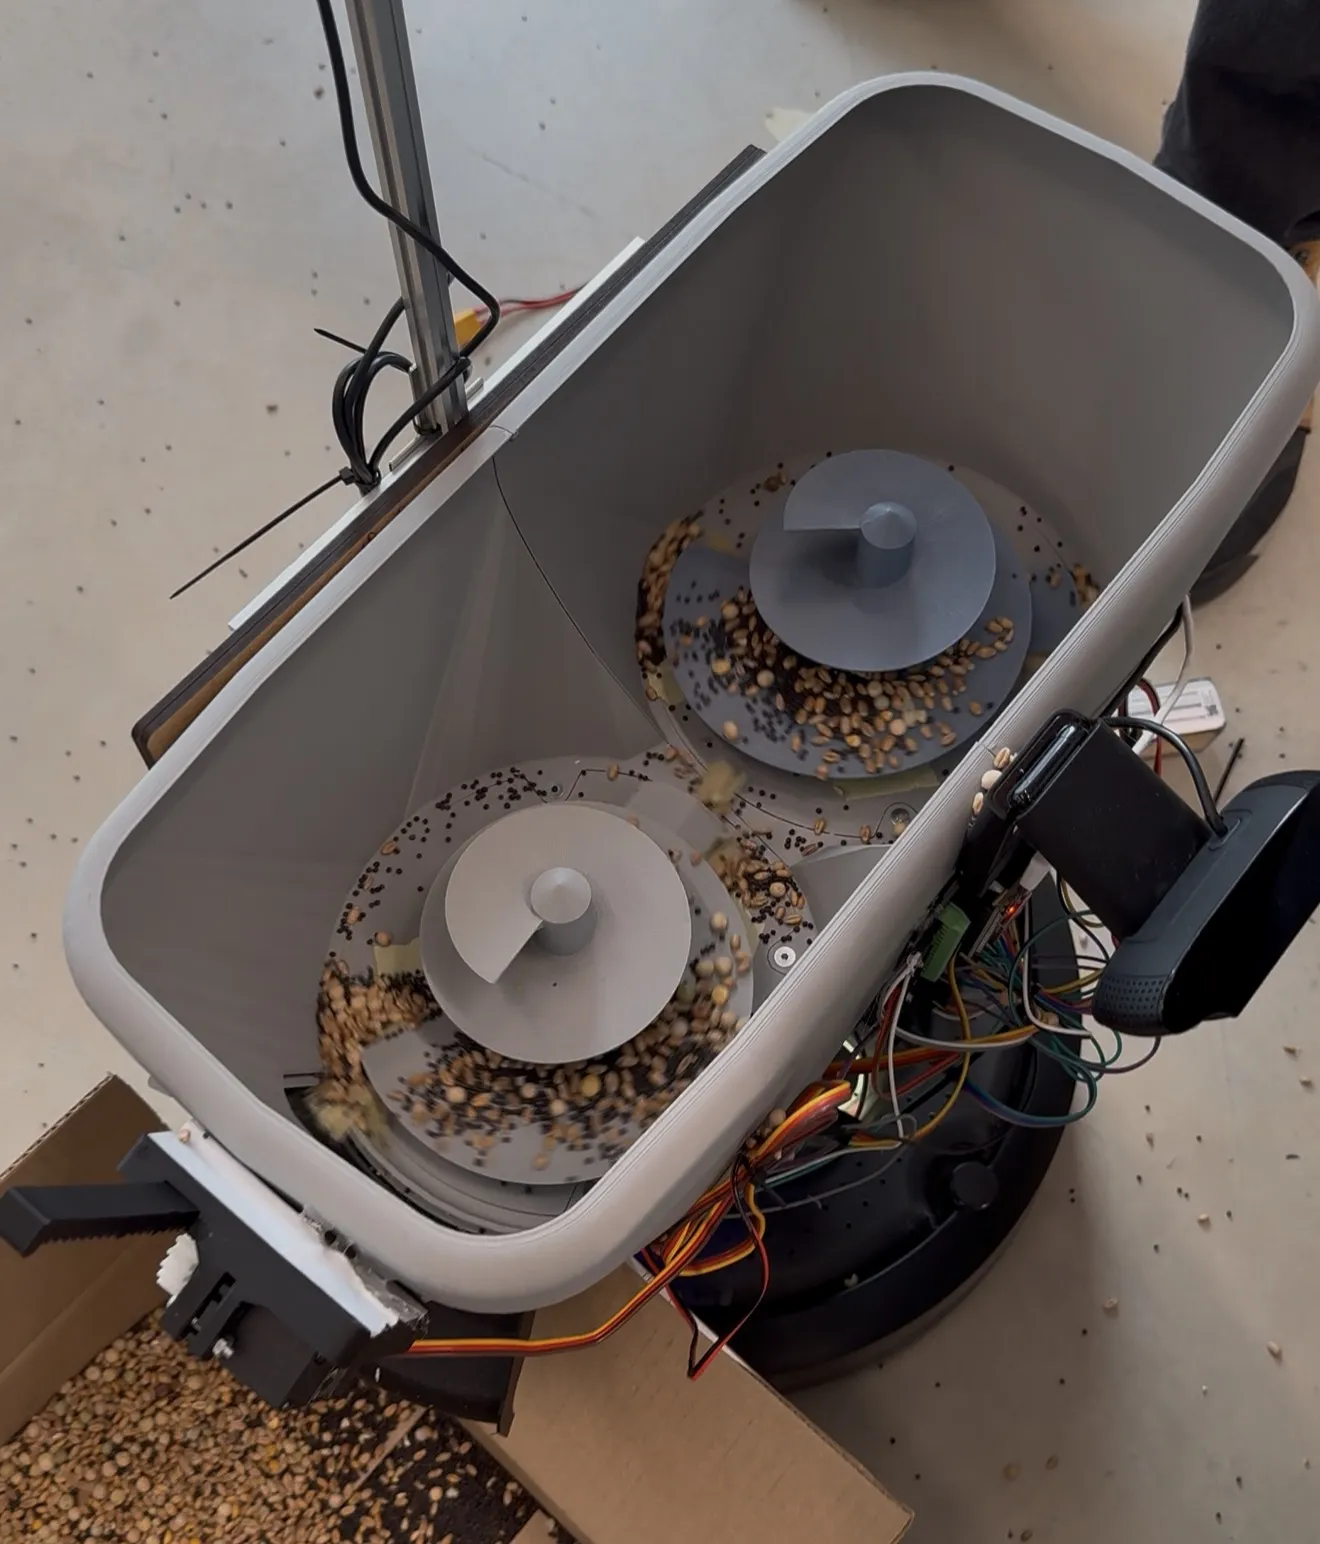
- Mix until the feed is homogeneous.
- Drive to the cows and feed them, stopping for any obstacle on the way.
- Return and dock.
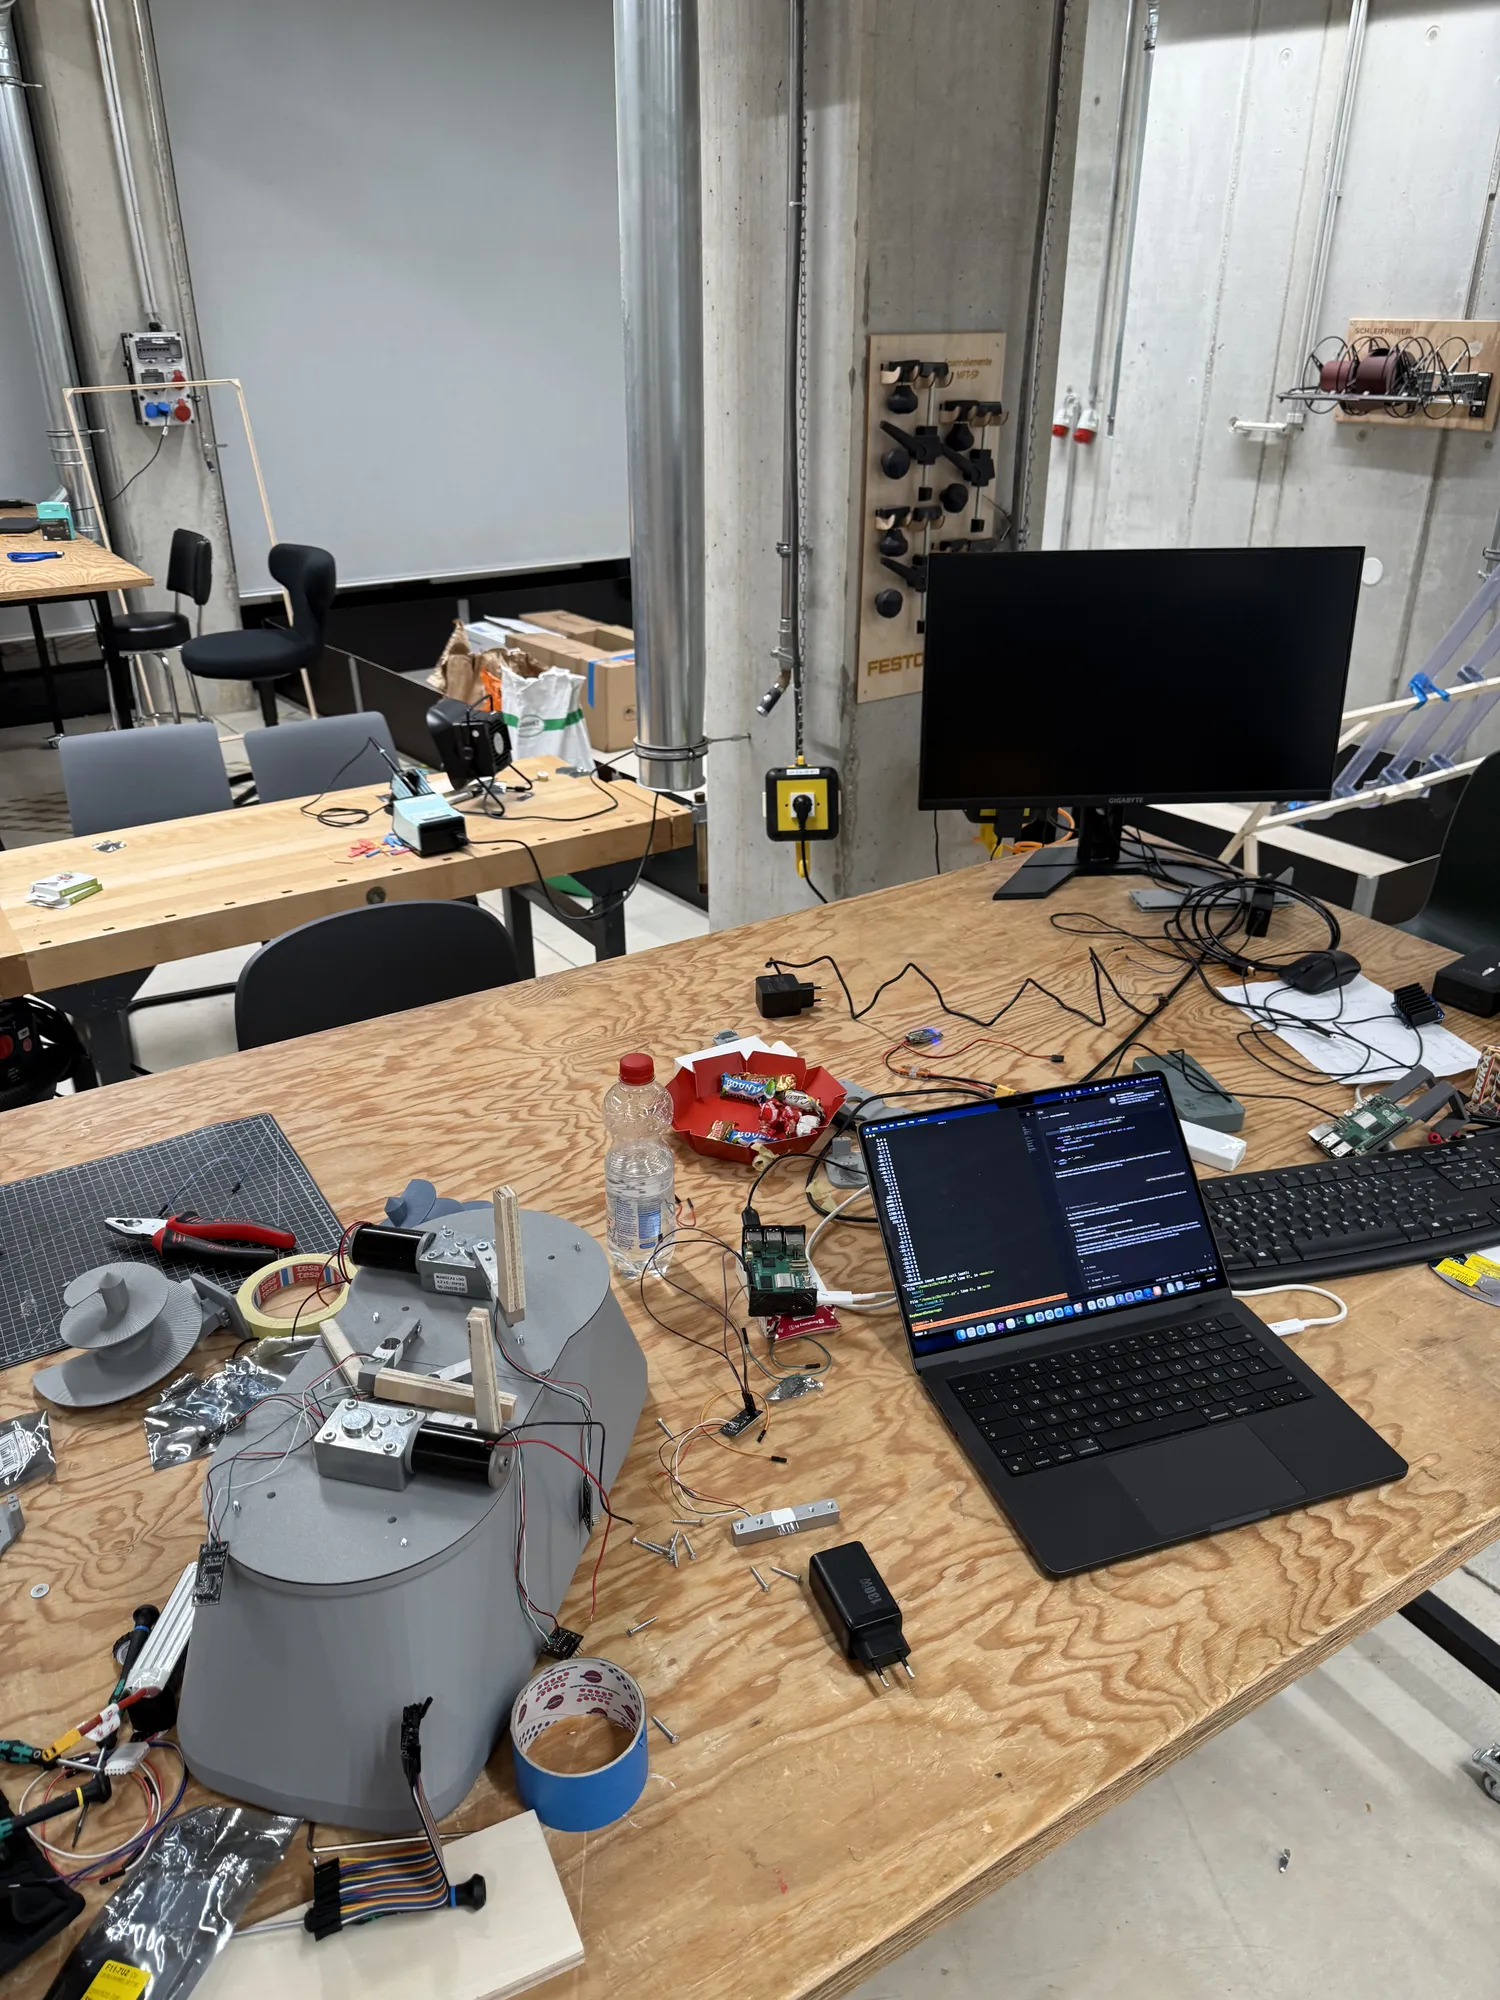
The pipeline runs across ESPs, load cells, motor controllers, a Raspberry Pi and a Jetson.
The test that convinced us
We started a full run and went for dinner. Twenty minutes later the cows had been fed and the robot was back in its dock.
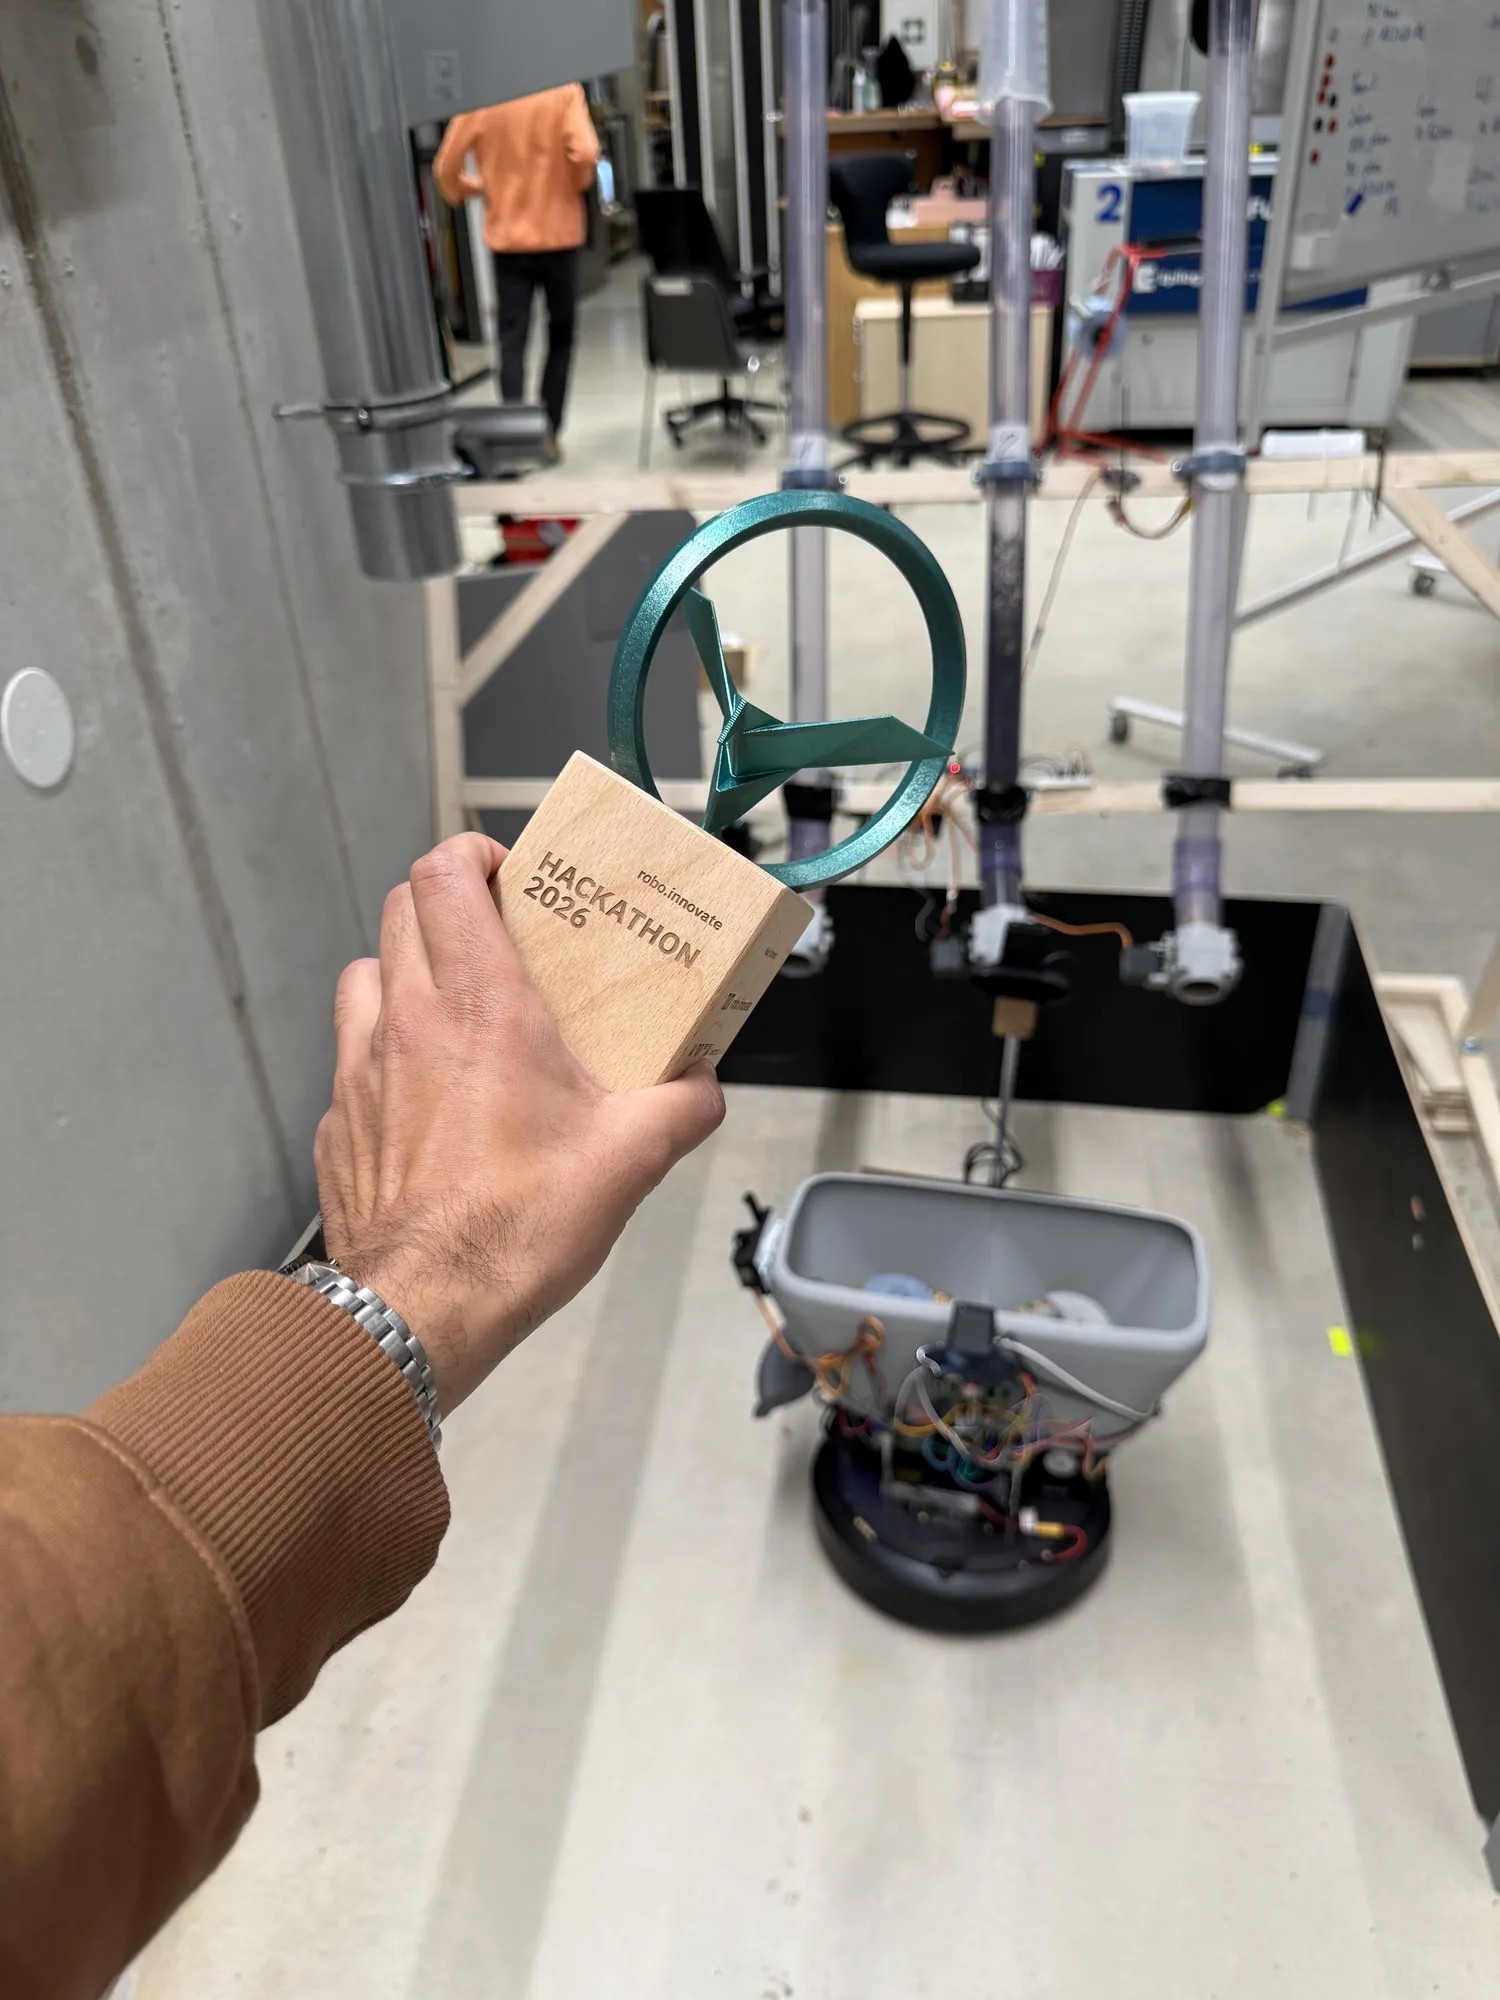
We won