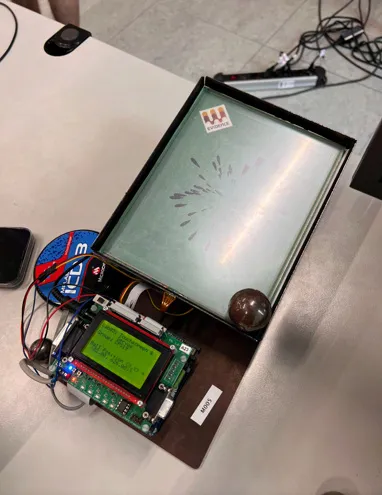
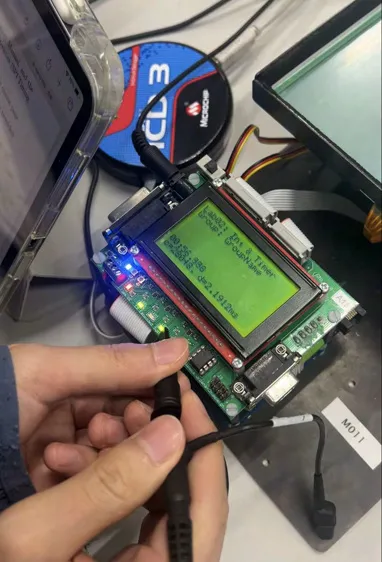
The final project of a semester-long embedded systems lab at TUM: stabilize a ball on a platform and make it follow a circle, programmed directly on a dsPIC33F.
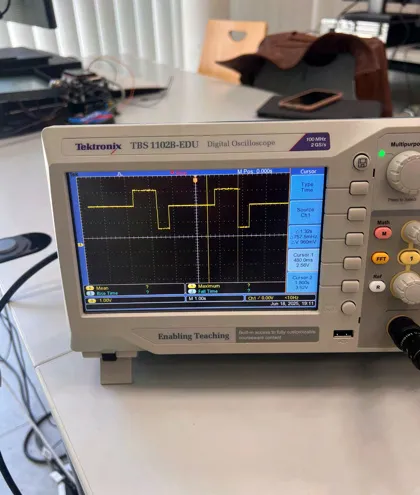
Low-level C reads the ball position from the resistive touchscreen, a tuned PD controller computes the correction, and PWM drives the two servos.